 BlinkThorLabs
CARLA-Based Parking Development System
In developmentBlinkThor Auto Parking
BlinkThor Auto Parking is a software product that our team is developing to simulate, implement and evaluate automated parking in CARLA. It brings parking algorithms, vehicle commands and simulation data into one workflow, making the complete maneuver observable from input information to final vehicle position.
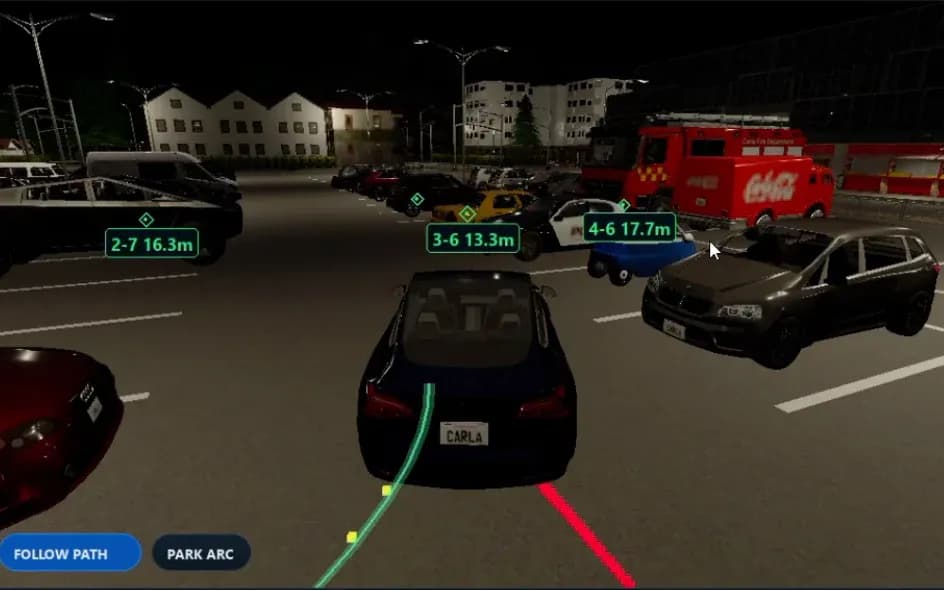
Automated parking, engineered as a complete maneuver
- Space understanding
- Path planning
- Closed-loop control
Challenge
A feasible path is only the beginning.
Approach
Vehicle geometry, maneuver states and controller response decide whether the planned motion can be executed.
Result
Inspect planning and control together in repeatable simulation scenarios.