 BlinkThorLabs
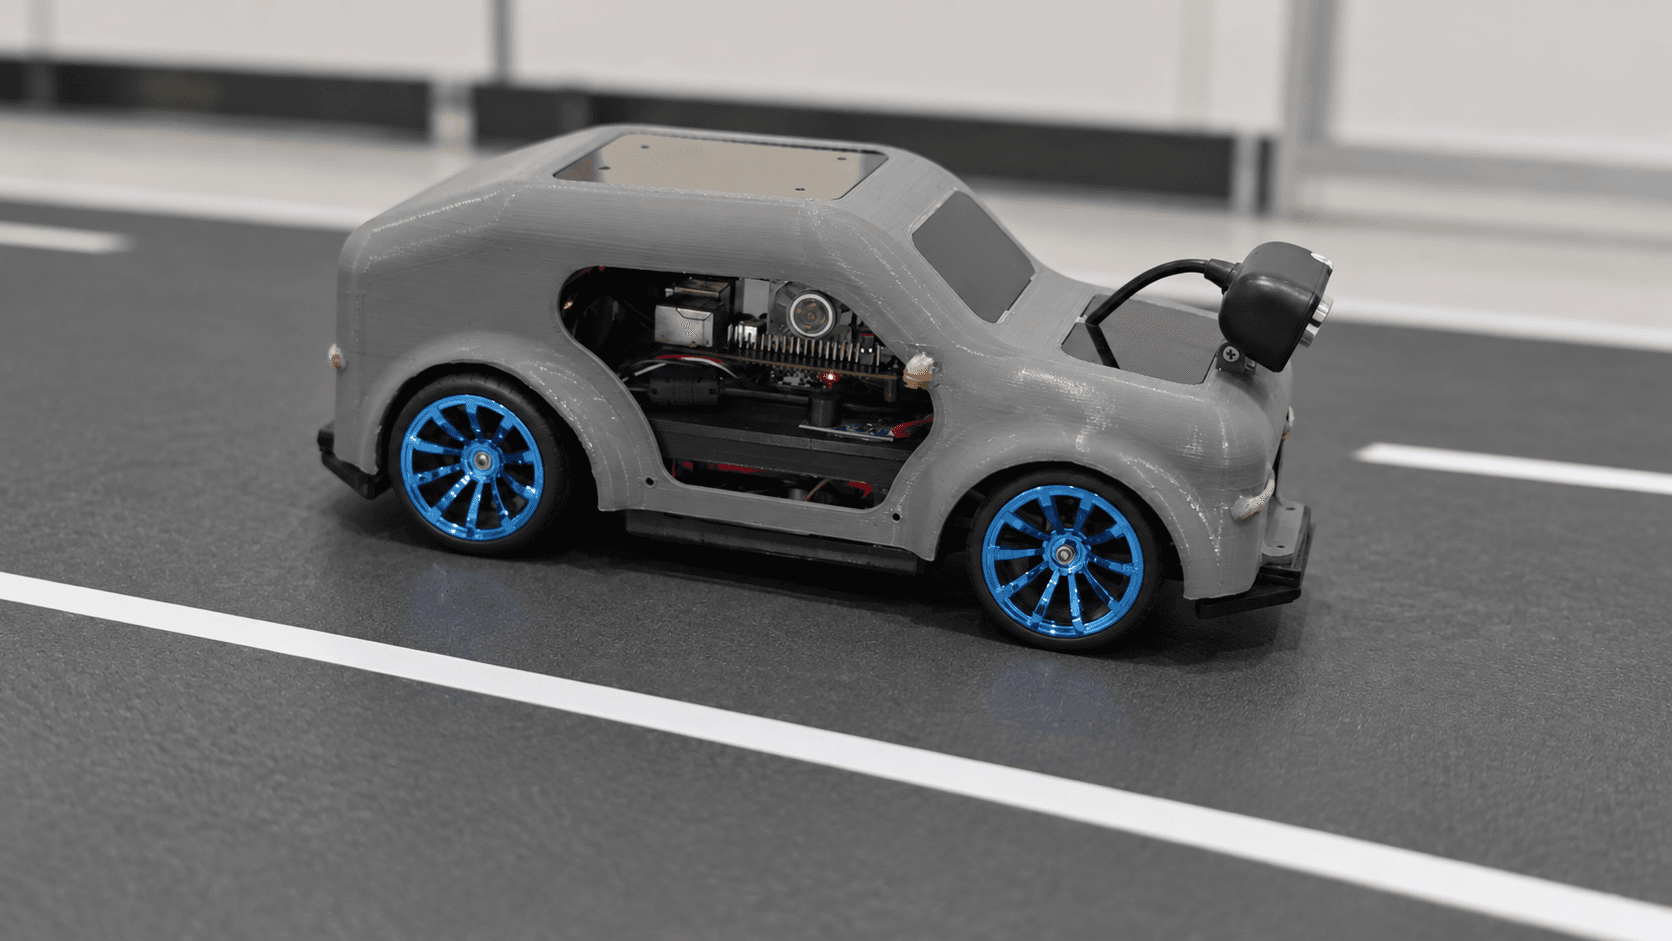
Why Does This Robot Need Two Brains?
A genuine question I had before I understood the answer: the Pi already runs Linux and ROS2. Why bolt on a whole separate microcontroller too?
Embedded & ADAS engineering
Deep write-ups on the embedded systems inside modern vehicles — the perception ECUs, real-time firmware, and safety-critical buses that turn camera, radar and LiDAR data into steering and braking. Written by engineers who ship it, not market it.
Test-track scenarios
Illustrative footage
We design embedded, robotics and automotive systems from A to Z, build them with your team, review what your engineers are building, or train them to do it themselves.
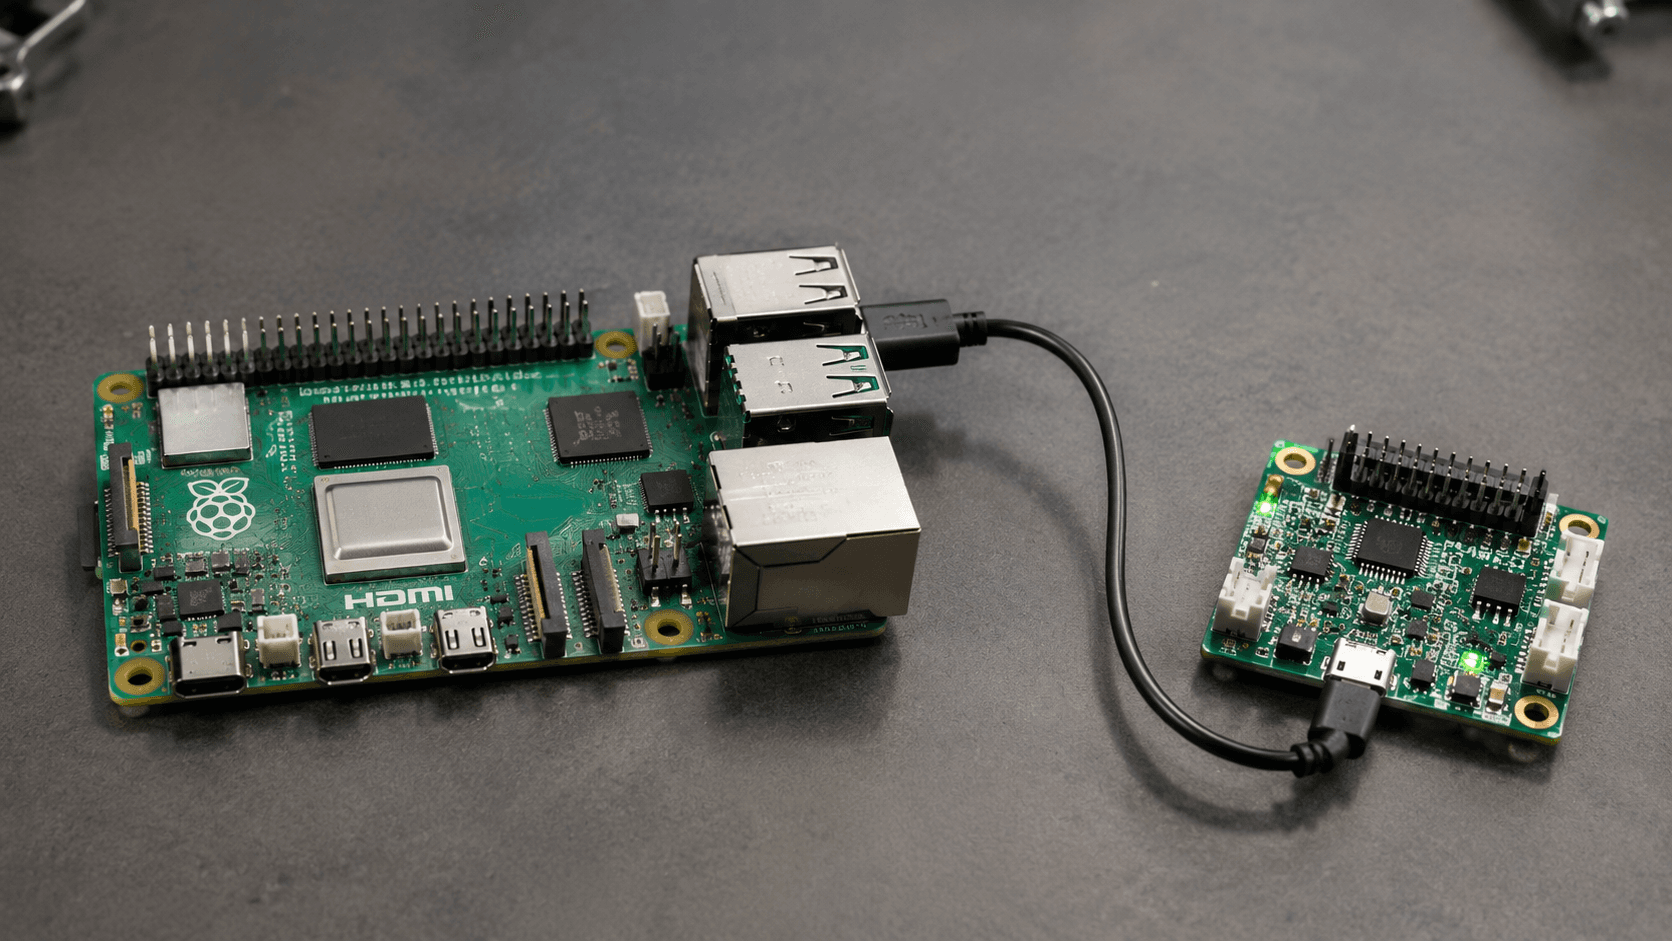 From our technical notes: Why Does This Robot Need Two Brains?Explore
We can work with you in 4 ways
Covers show product concepts or frames from recorded demos.
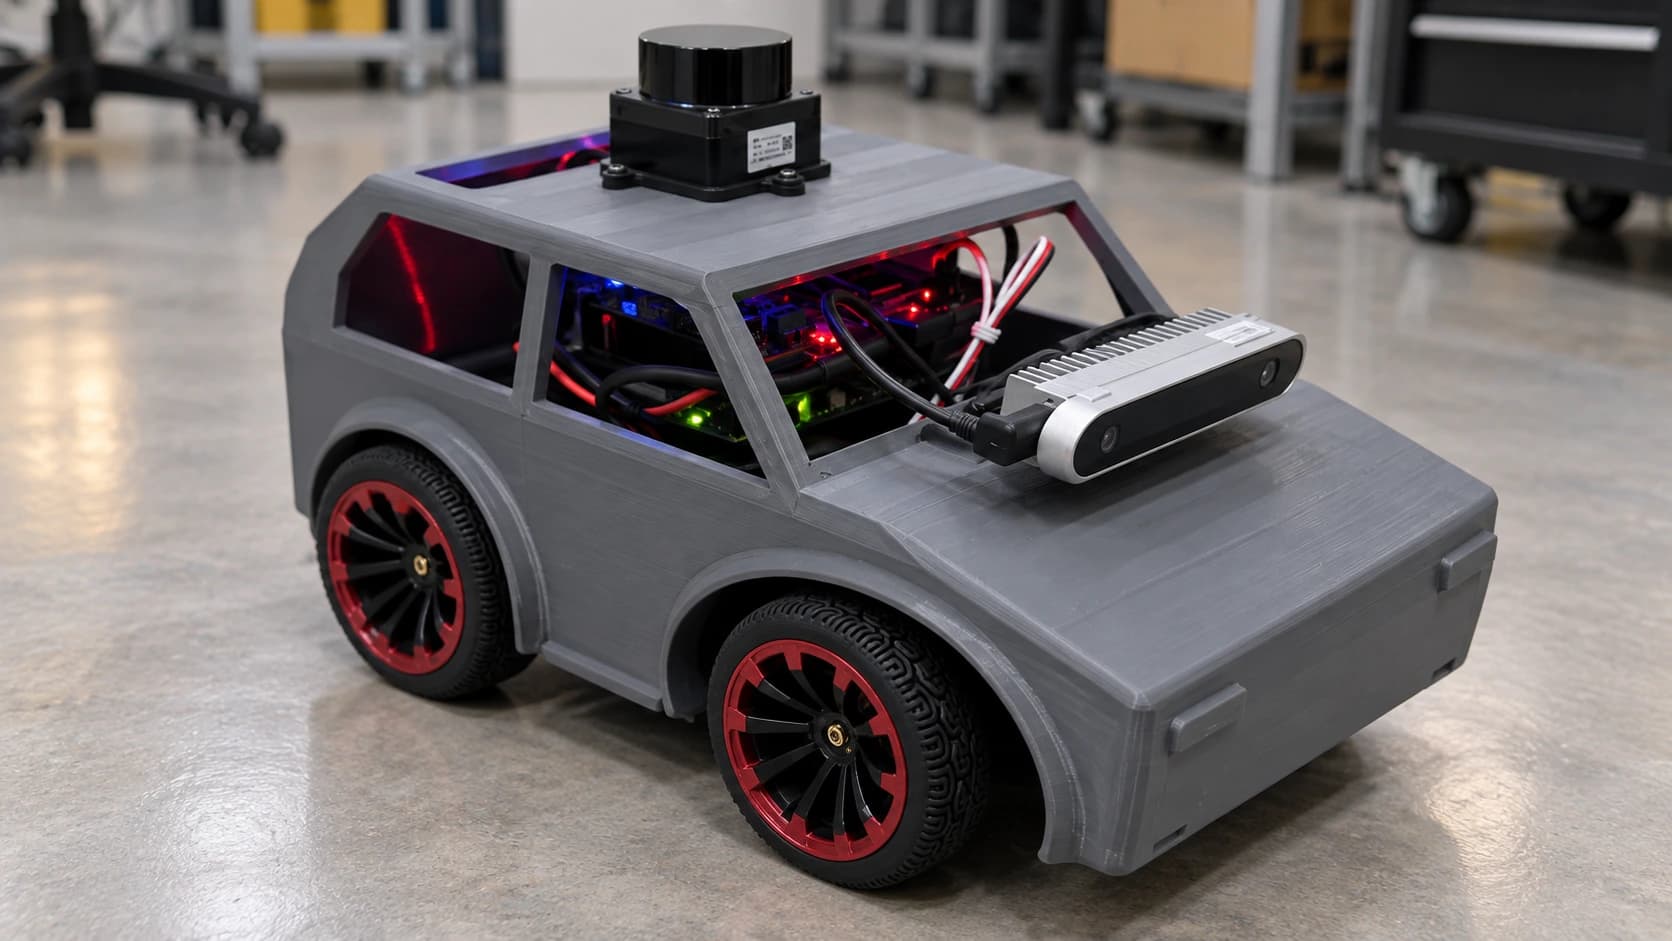
BlinkThor ROS 2 Robot is our team’s mobile robotics project built on the Hiwonder MentorPi A1 platform. It combines a compact vehicle-style chassis with a programmable robotics environment, providing a physical foundation for vision applications, motion behaviors and software integration.
View product overview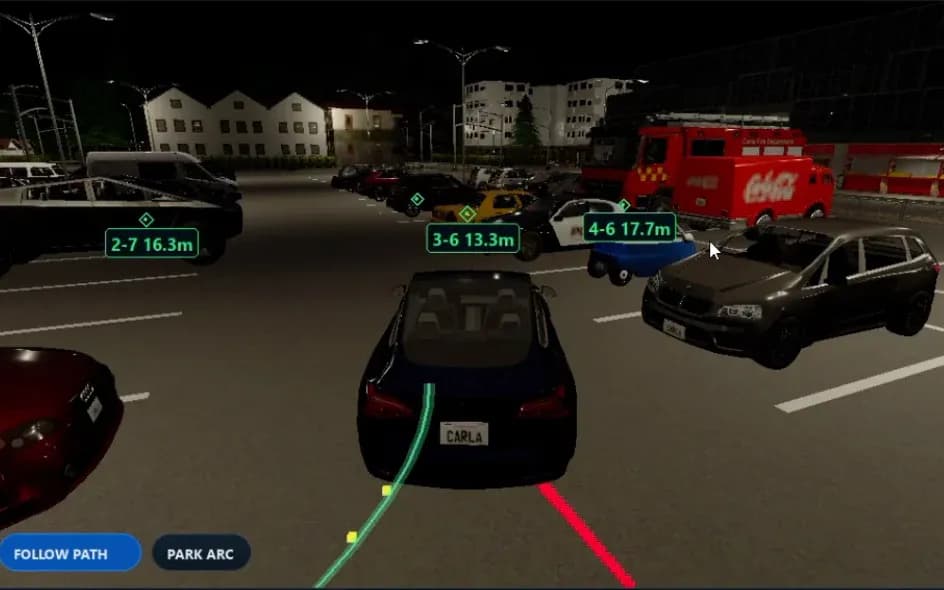
BlinkThor Auto Parking is a software product that our team is developing to simulate, implement and evaluate automated parking in CARLA. It brings parking algorithms, vehicle commands and simulation data into one workflow, making the complete maneuver observable from input information to final vehicle position.
View product overview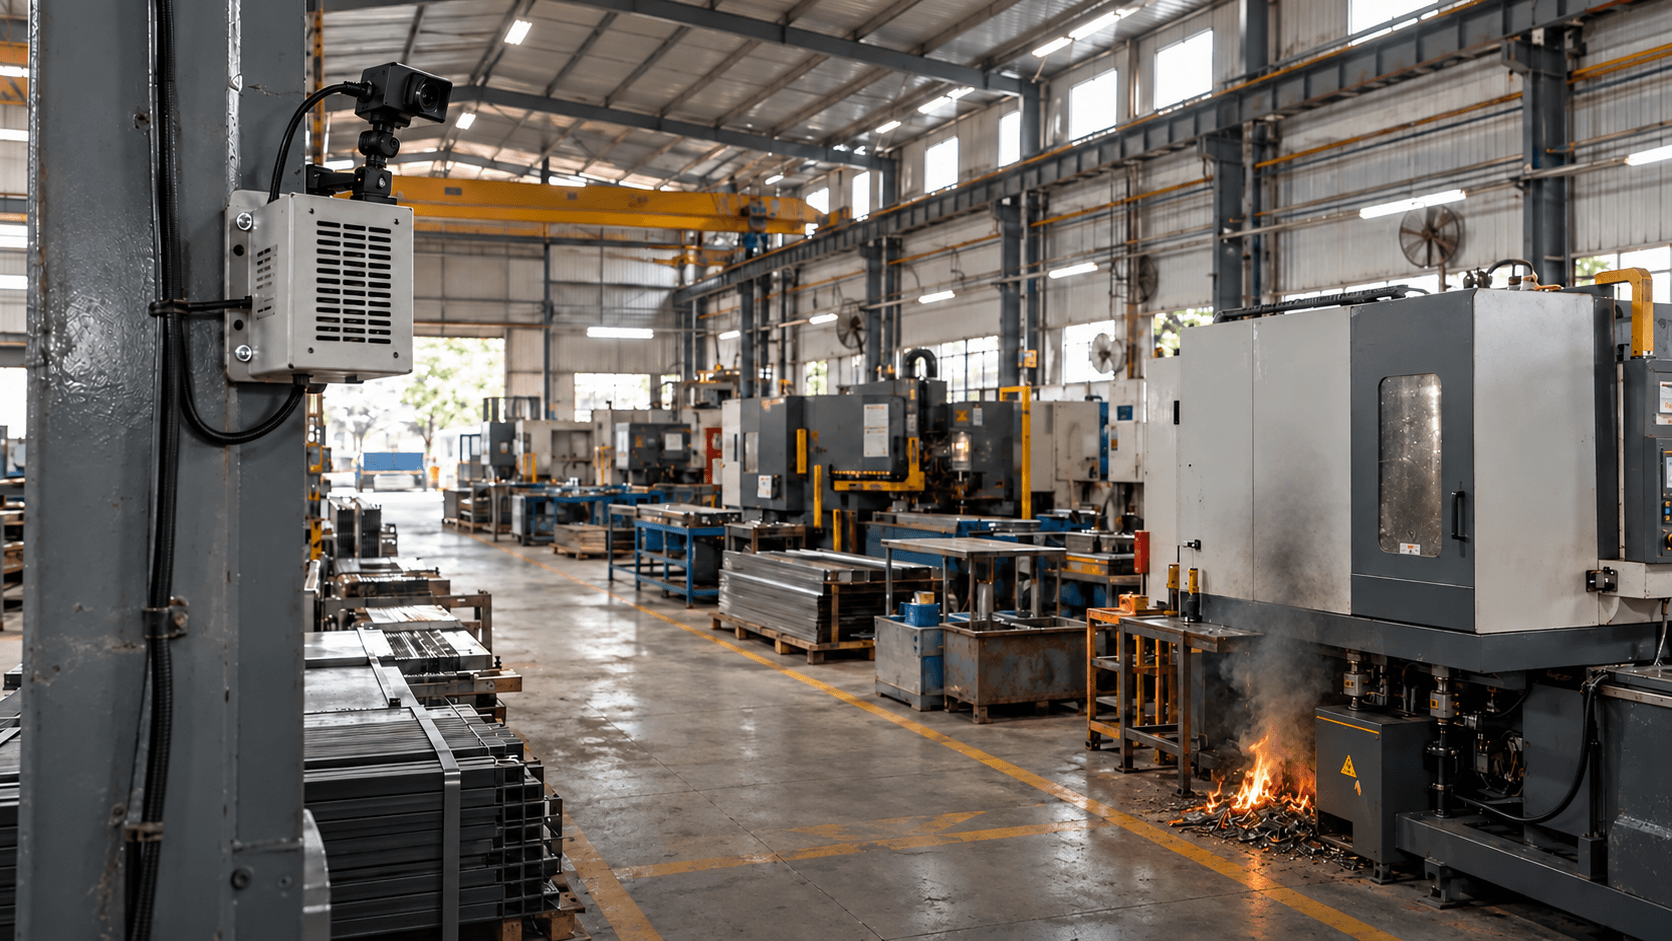
BlinkThor AI Fire Detection connects camera imagery, candidate-fire recognition and operator review. Our team develops visual monitoring workflows around the site, from usable camera evidence and event logic to notification integration and review applications.
View product overview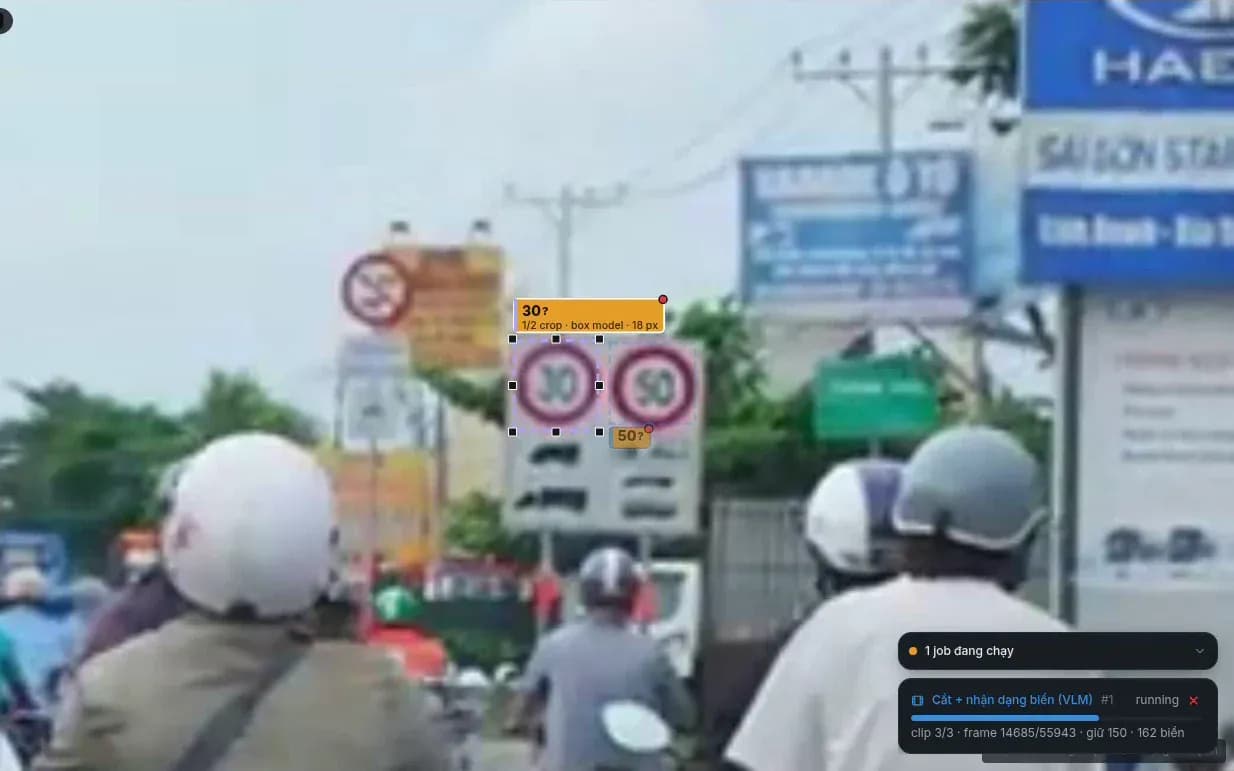
BlinkThor AutoLabel AI is a data annotation product that our team is developing to automate labeling and prepare datasets for different model-training workflows. It helps turn raw visual data into structured annotations, reducing repetitive preparation while keeping labels available for inspection and correction.
View product overview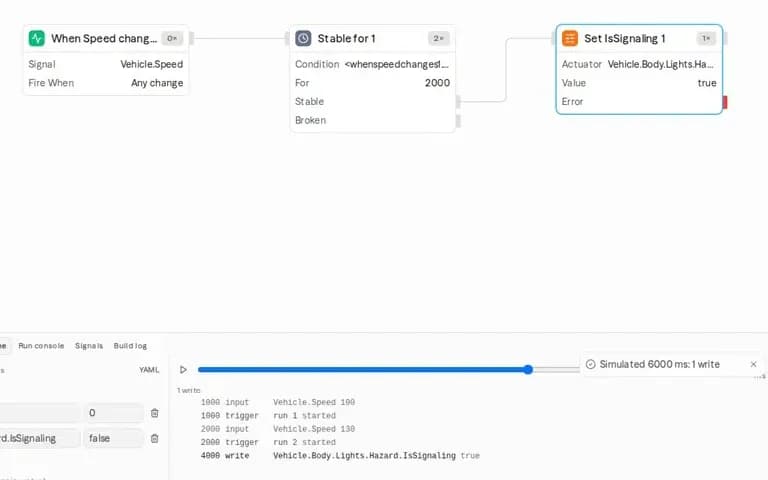
BlinkThor SimVehicleApp is a no-code test studio our team is developing for software-defined vehicle functions. Engineers compose vehicle behaviour from COVESA VSS signal blocks, simulate it against timed inputs, compile it deterministically into an Eclipse Velocitas vehicle app and run that app on a real KUKSA Databroker, all before the function reaches a vehicle.
View product overview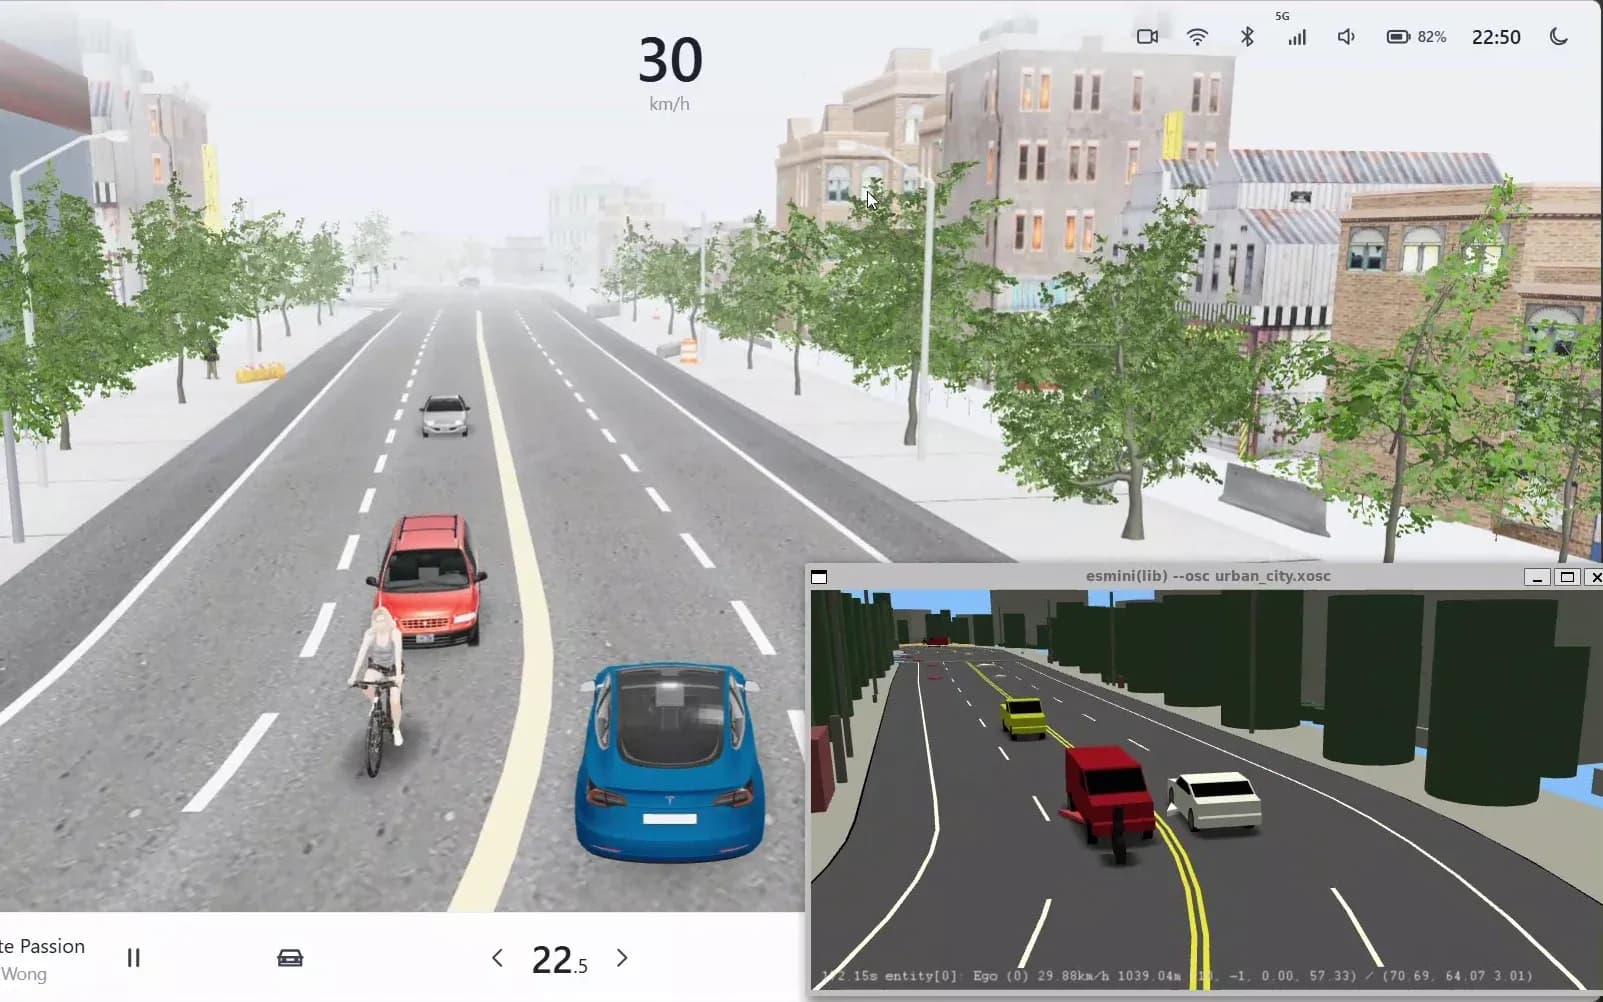
BlinkThor HMI Simulator is an HMI and driving-scenario simulation product our team is developing. OpenSCENARIO files define the road, the traffic and the ego vehicle; a scenario engine plays them step by step and streams the world state to a web driver display, so interface designs are built and reviewed against moving traffic instead of static mock-ups.
View product overview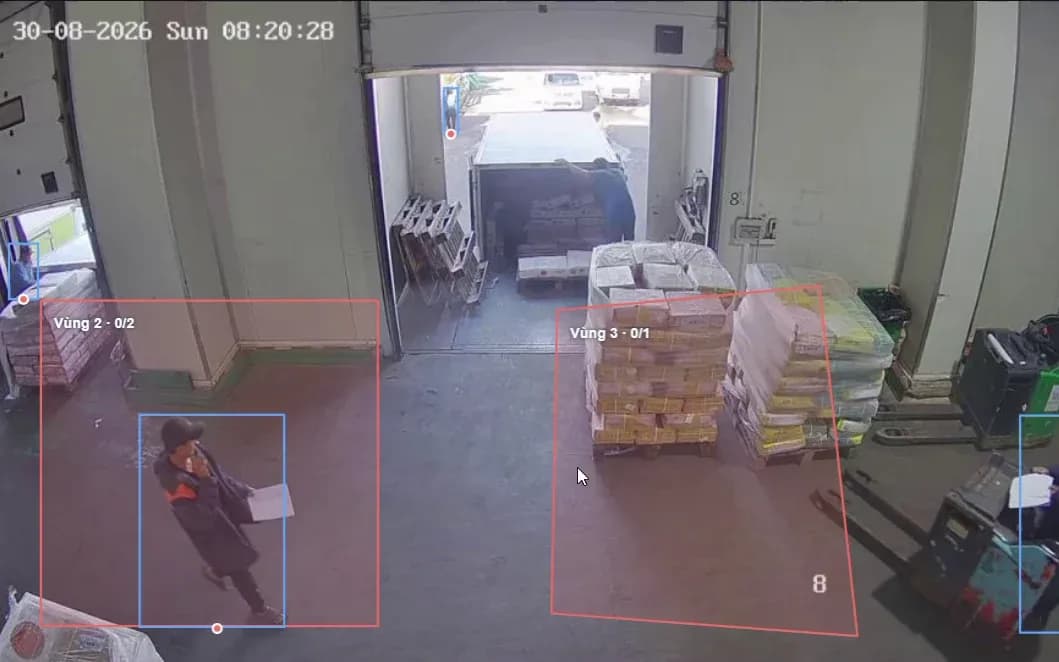
BlinkThor Factory Zone Monitoring is an AI camera monitoring system our team is developing for factories and workshops. Supervisors draw zones on each camera image and set a staffing rule for every zone; an on-machine AI model counts the people in each zone and raises an alert, with the frame as evidence, when a position stays short longer than allowed.
View product overview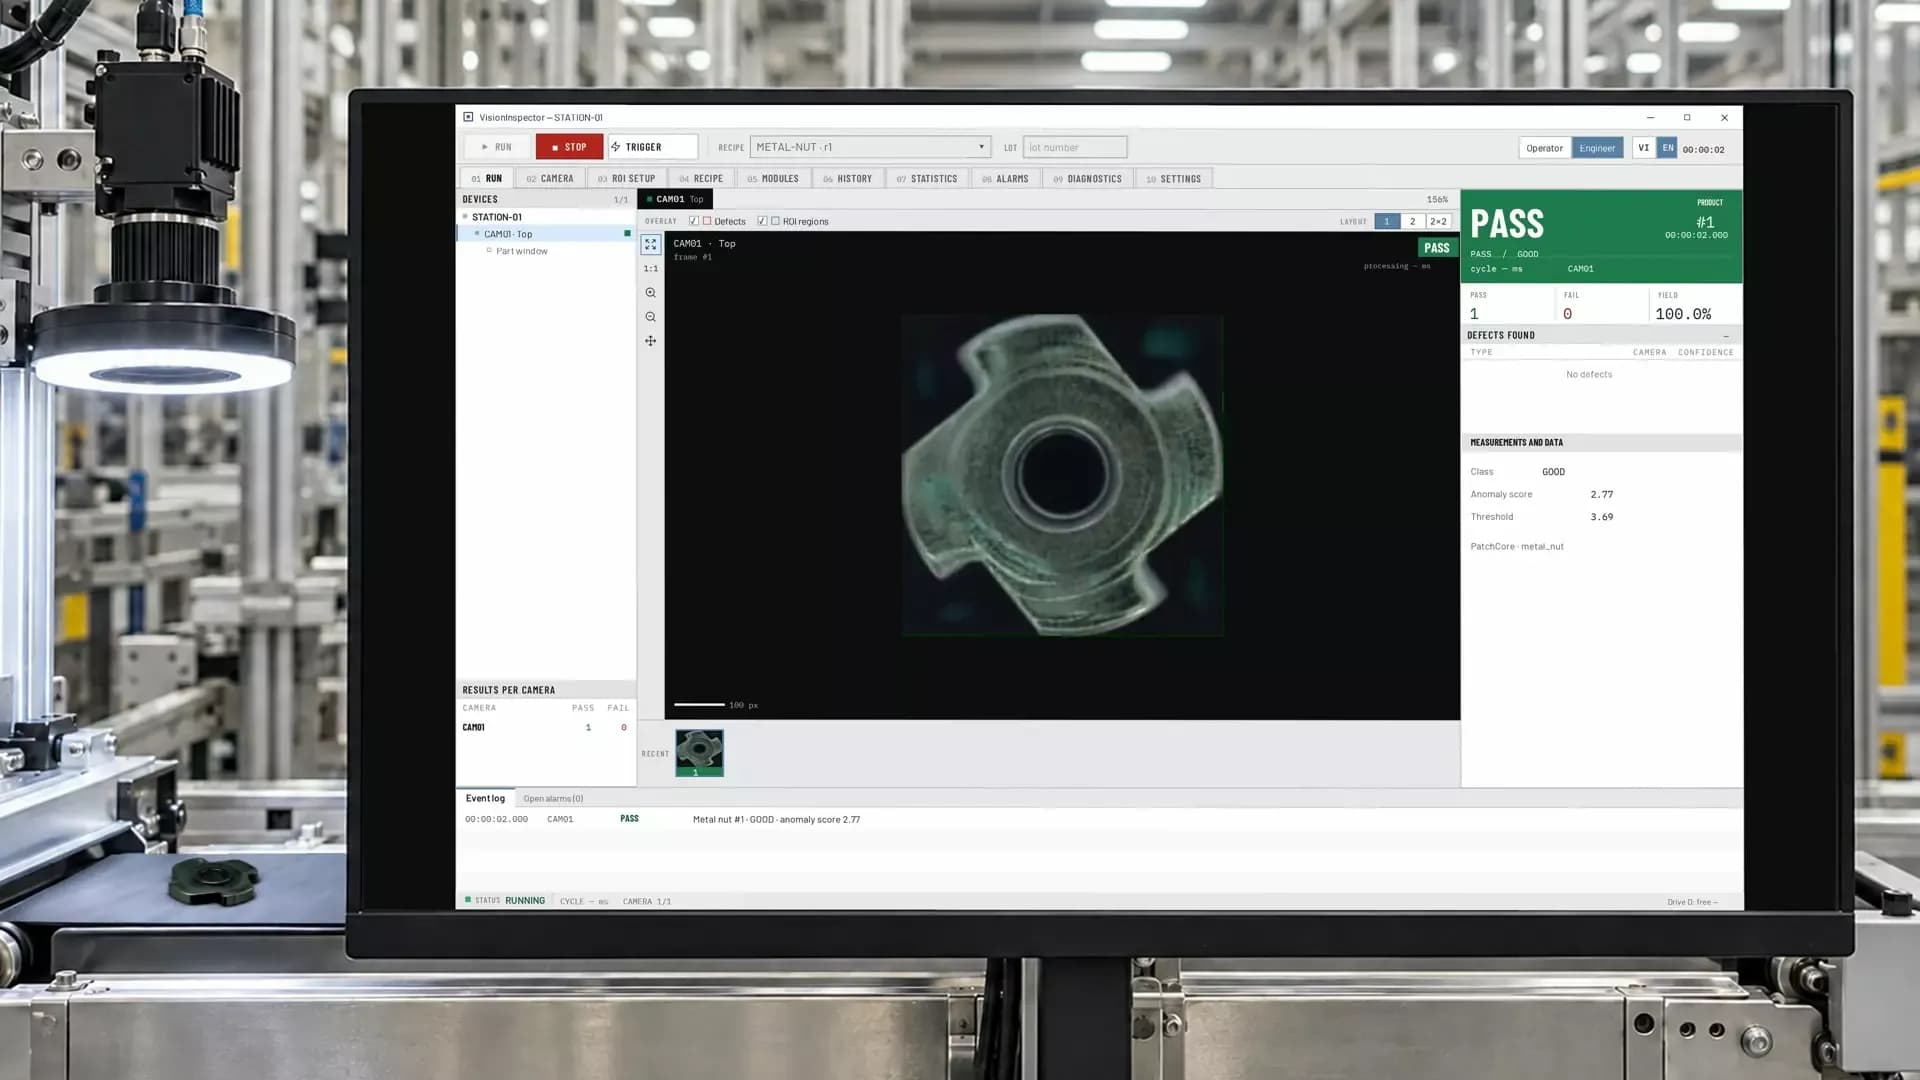
Machine-vision inspection software that connects industrial cameras, product recipes and replaceable processing modules with an operator workspace. Build part-specific quality checks, retain visual evidence and adapt the station as inspection requirements change.
View product overviewADAS feature explainer
A concise simulation of how perception, longitudinal control and lane support cooperate around the driver.
Reference architecture
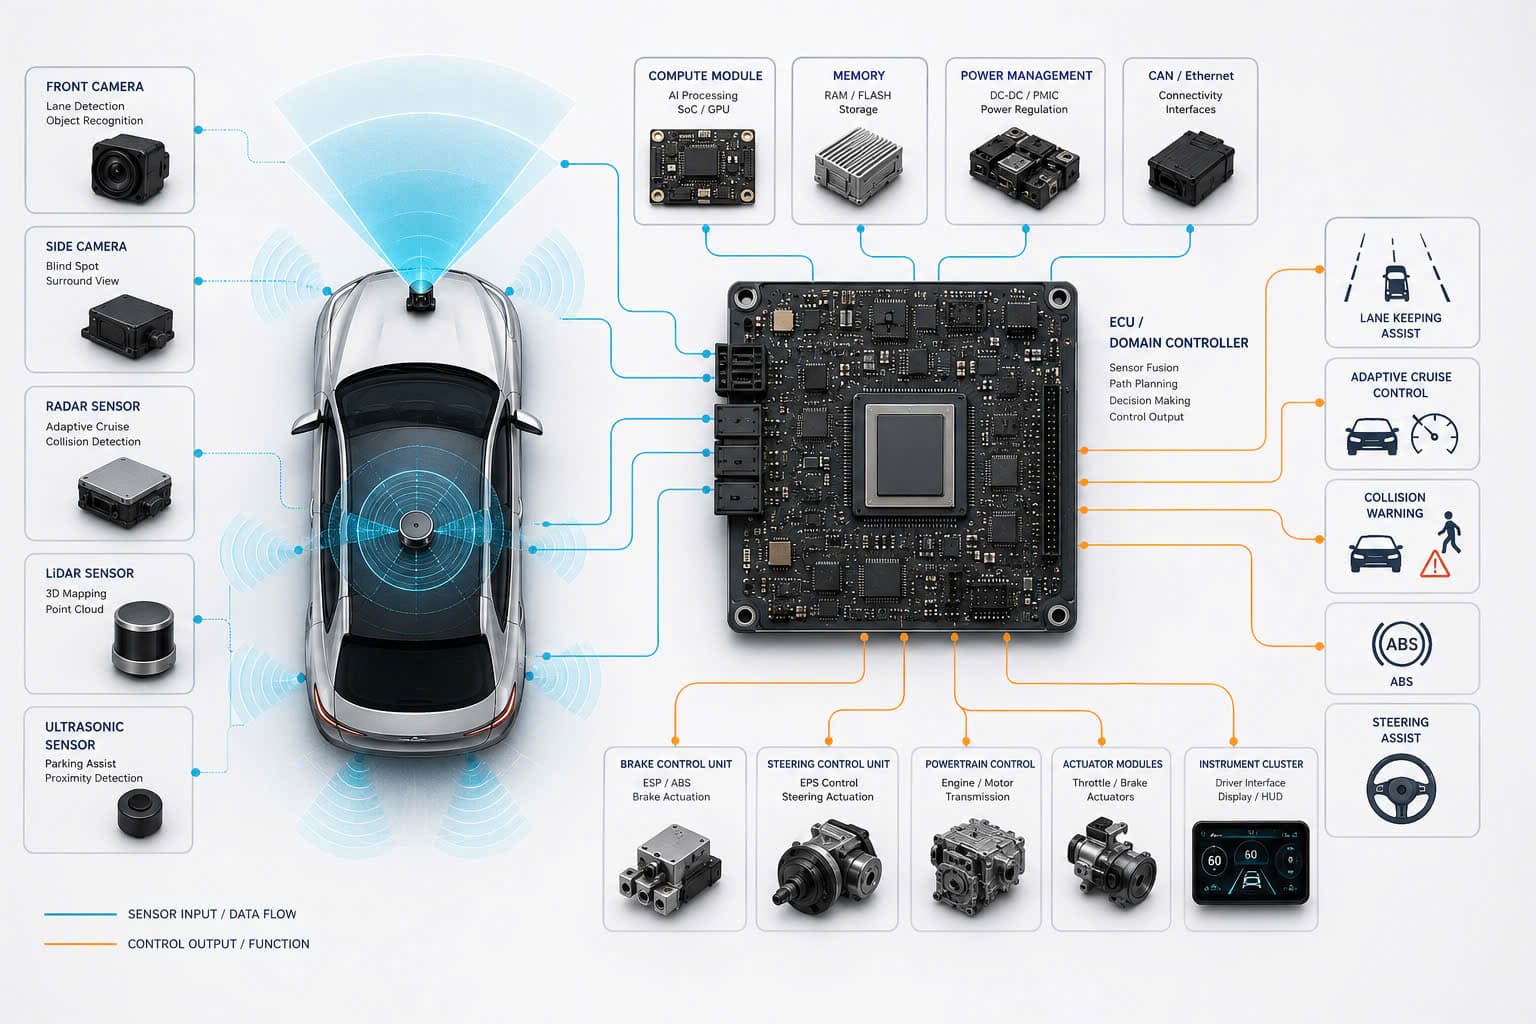
The ADAS architecture our notes keep coming back to: camera, radar, LiDAR and ultrasonic sensors feeding a domain controller, and the brake, steering and powertrain ECUs that act on its decisions.
Prototype builds, weekend hacks, and the first time a demo actually drives itself.
BSW layers, RTE generation, and the ARXML config change that breaks a build six weeks later
LatestAUTOSAR Classic vs Adaptive: Picking the Right One Isn't About Which Is Newer
Bare-metal drivers, RTOS scheduling, and the bugs that only show up at -40°C.
LatestThe Silent Killer: Stack Overflow in a System With No Stack Protector
CAN, CAN-FD, and LIN diagnostics that keep a bus from silently dying.
LatestUDS Diagnostics Over DoIP: What Actually Changes When You Move Off CAN
Kalman filters, camera-radar fusion, and the sensor stack behind lane-keep.
ISO/SAE 21434, rollback protection, and the threat models that keep a bootloader honest.
YOLO models, dataset edge cases, and the simulation gap between synthetic rain and the real thing.
LatestSimulating Rain: Why Our LiDAR Model Lied to Us in CARLA
ISO 26262 in practice: FMEAs, ASIL decomposition, and safety cases that survive audit.
LatestWe Automated 80% of Our HIL Regression Suite. Here's What Broke First.
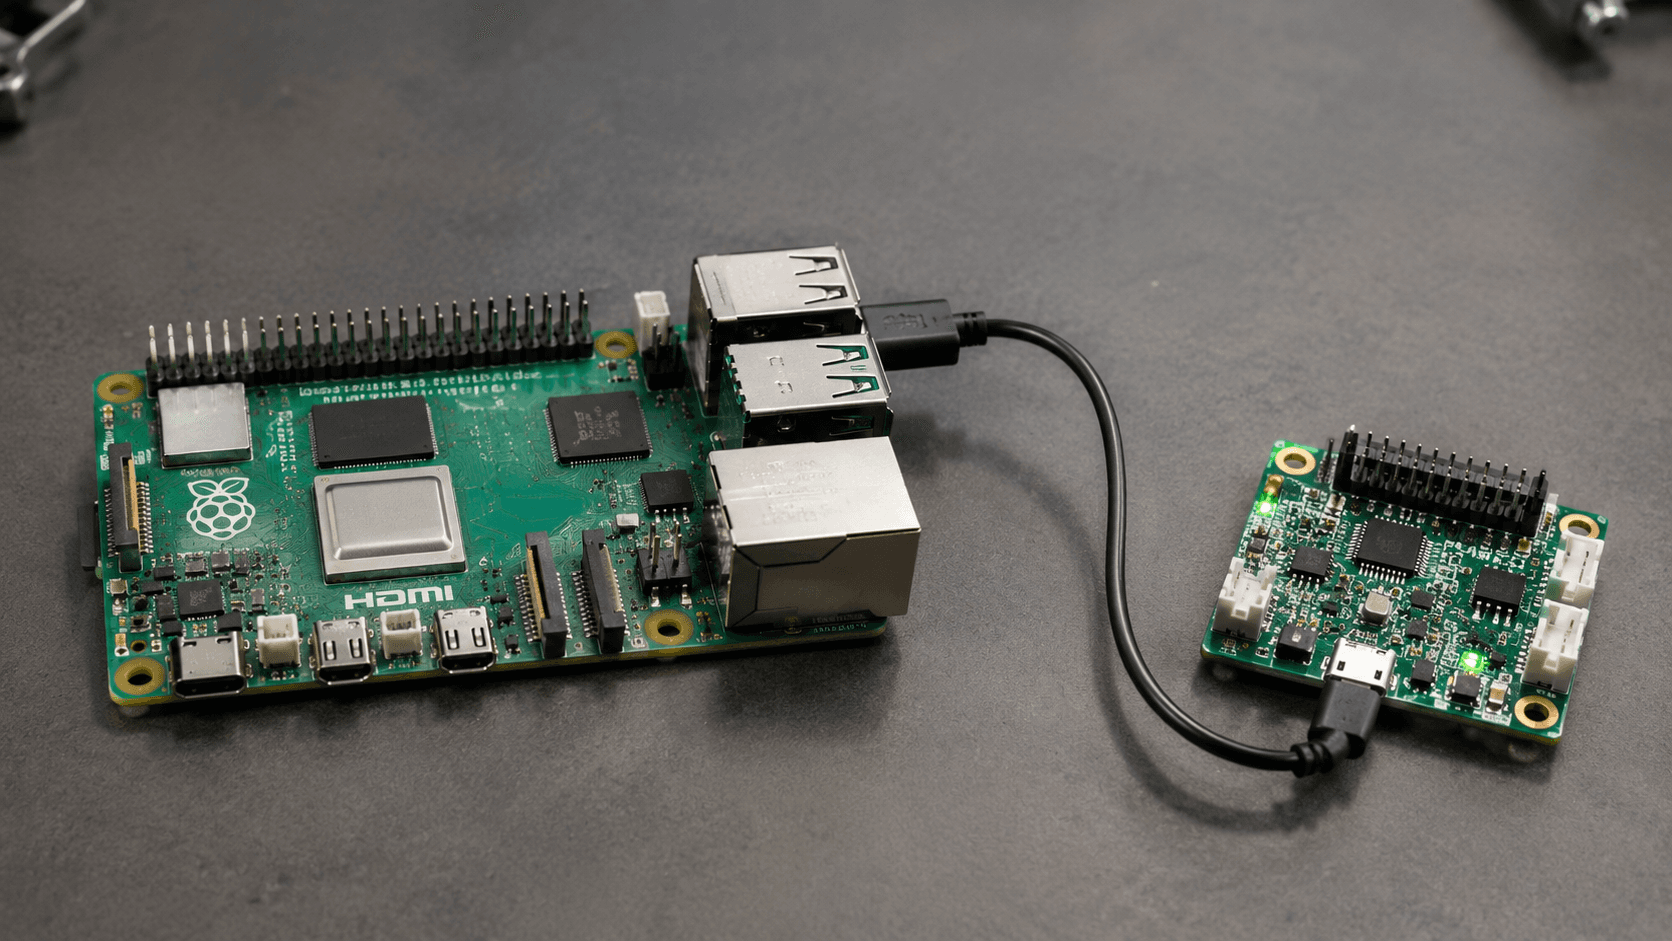
A genuine question I had before I understood the answer: the Pi already runs Linux and ROS2. Why bolt on a whole separate microcontroller too?
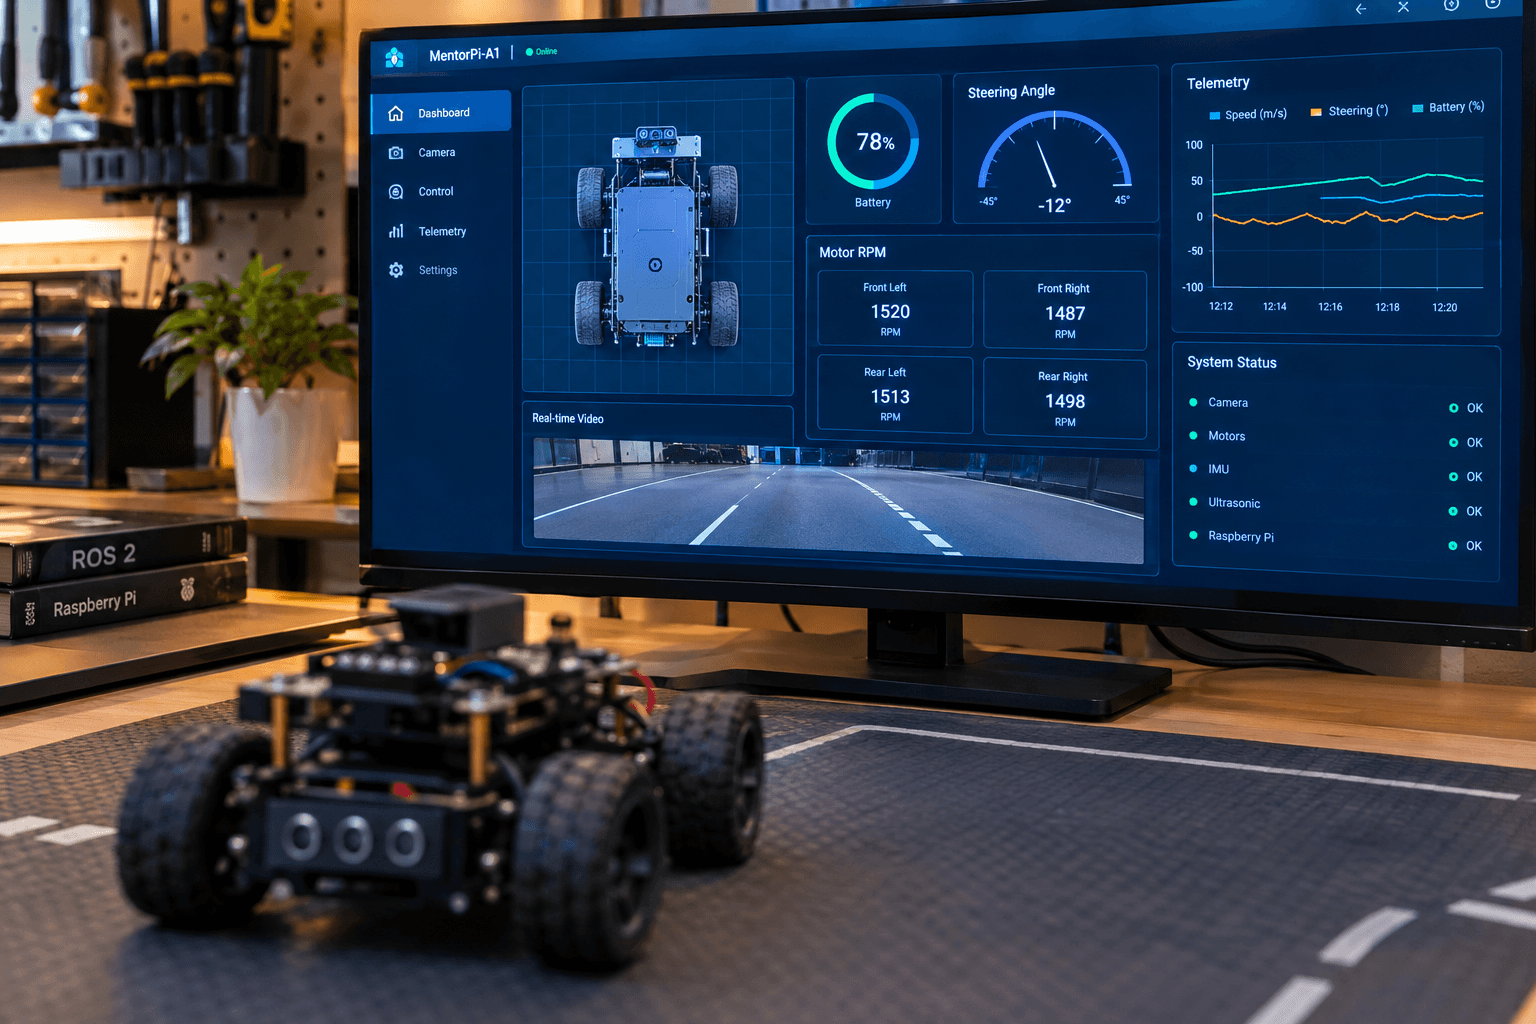
We didn't build the twin to look impressive in a demo. We built it because I was tired of guessing what the robot "felt" from the outside.
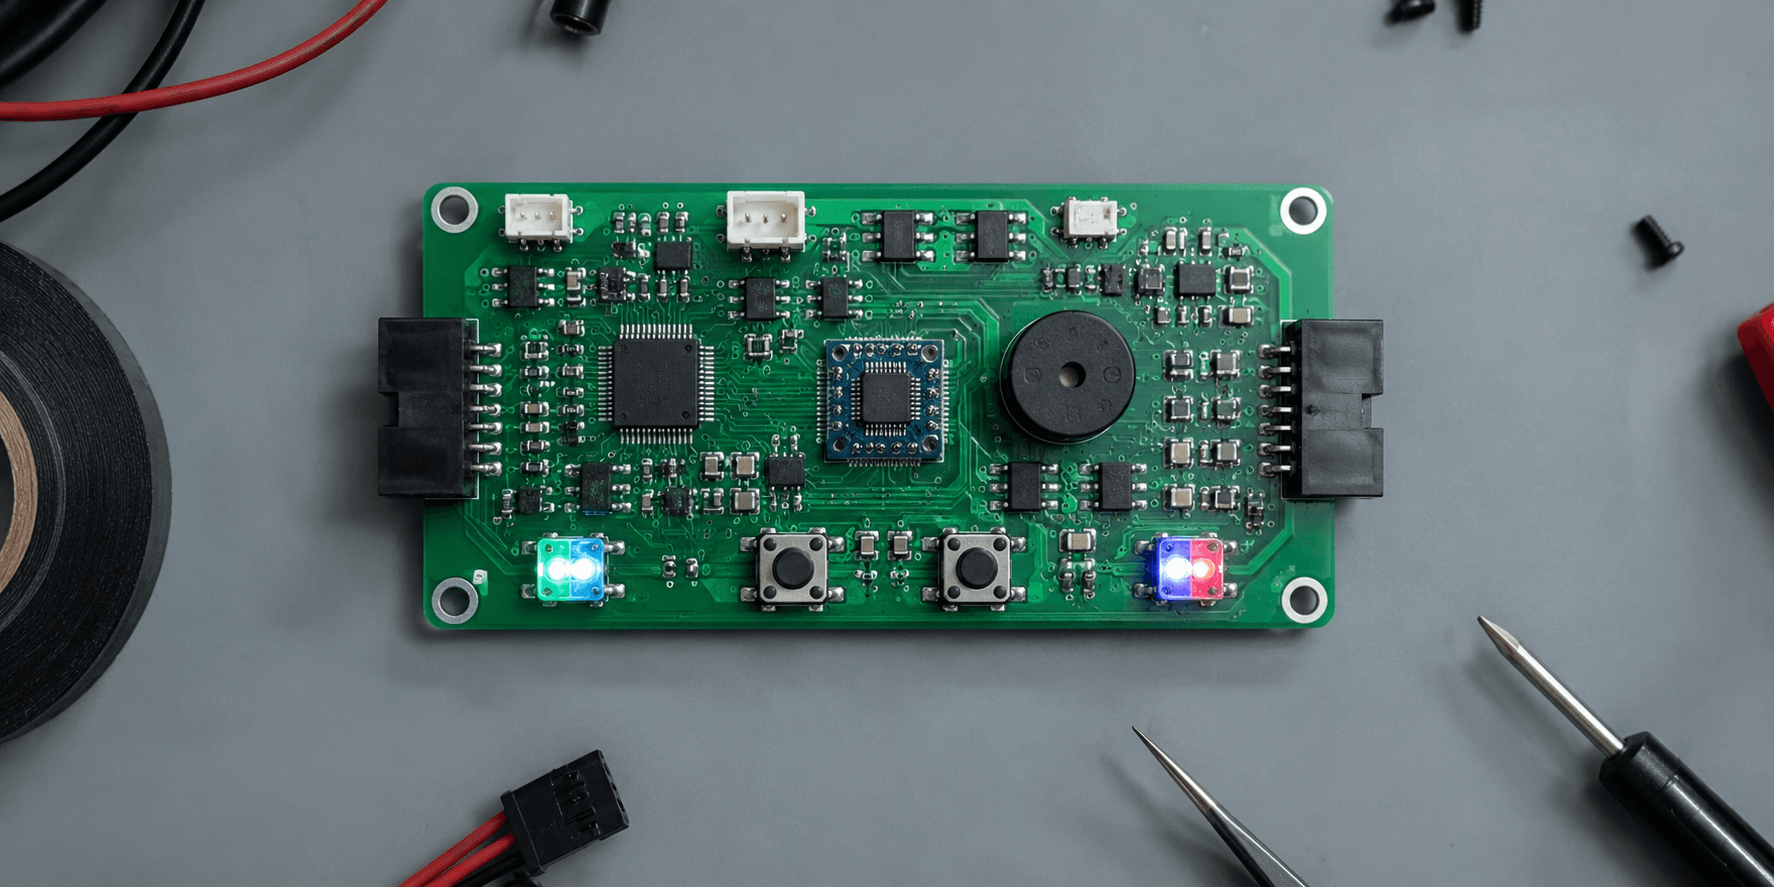
Five parts I walked right past on my way to the big square chip in the middle. They deserved better.
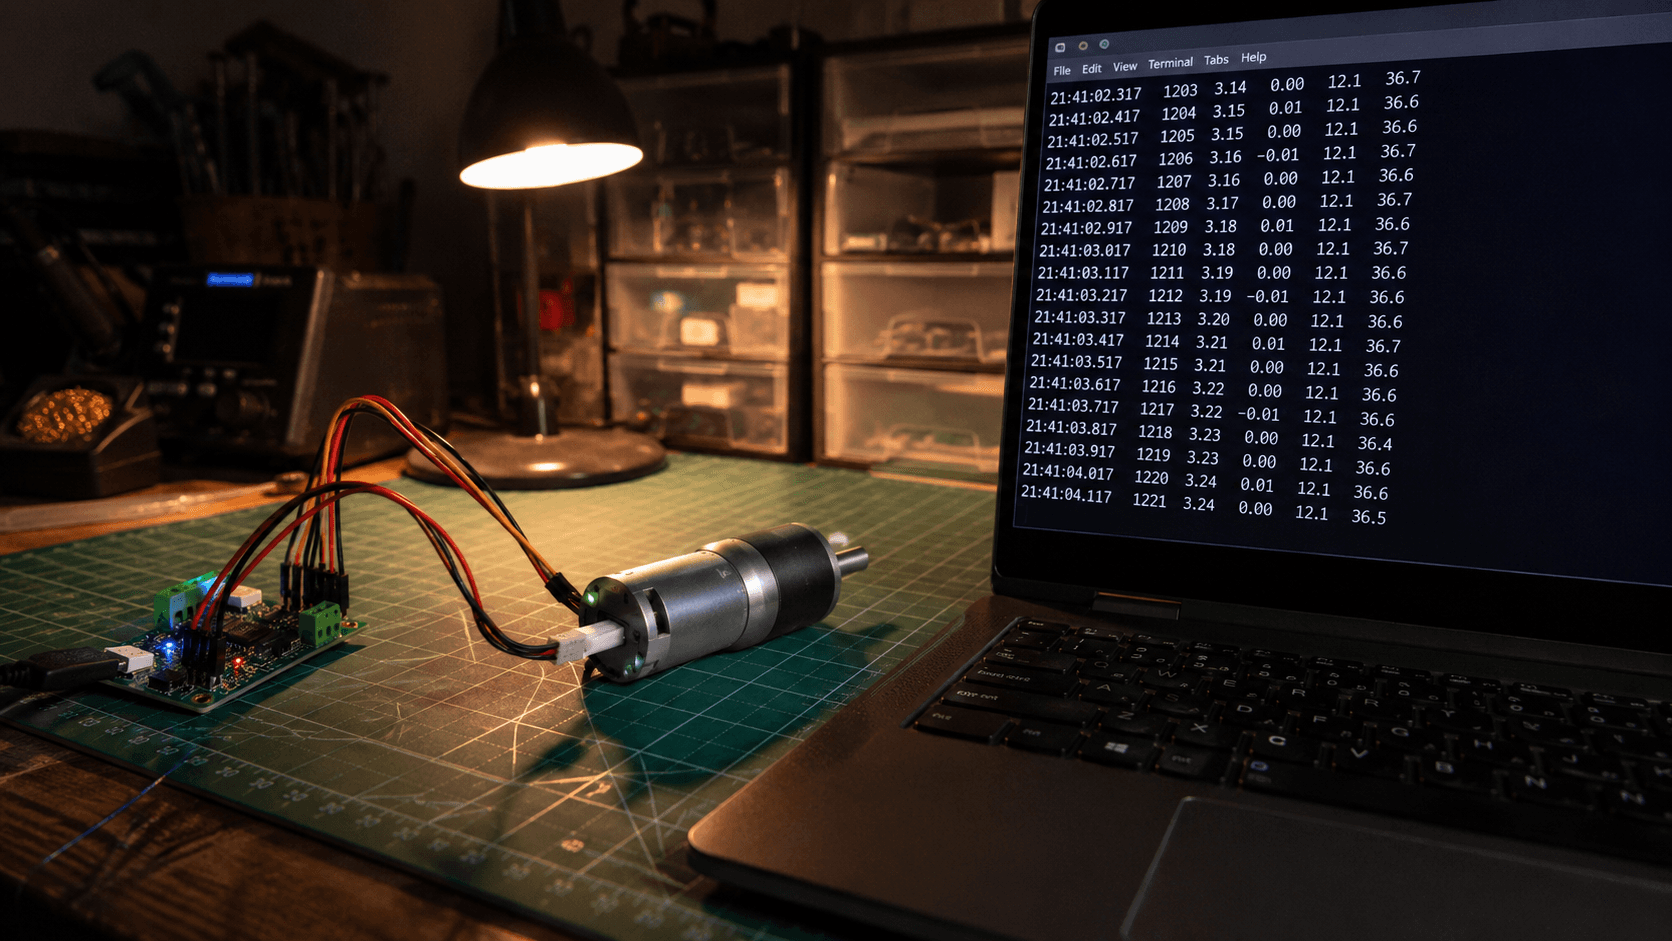
"set" said 1.000. "actual" never quite agreed with it. That disagreement is the whole lesson.
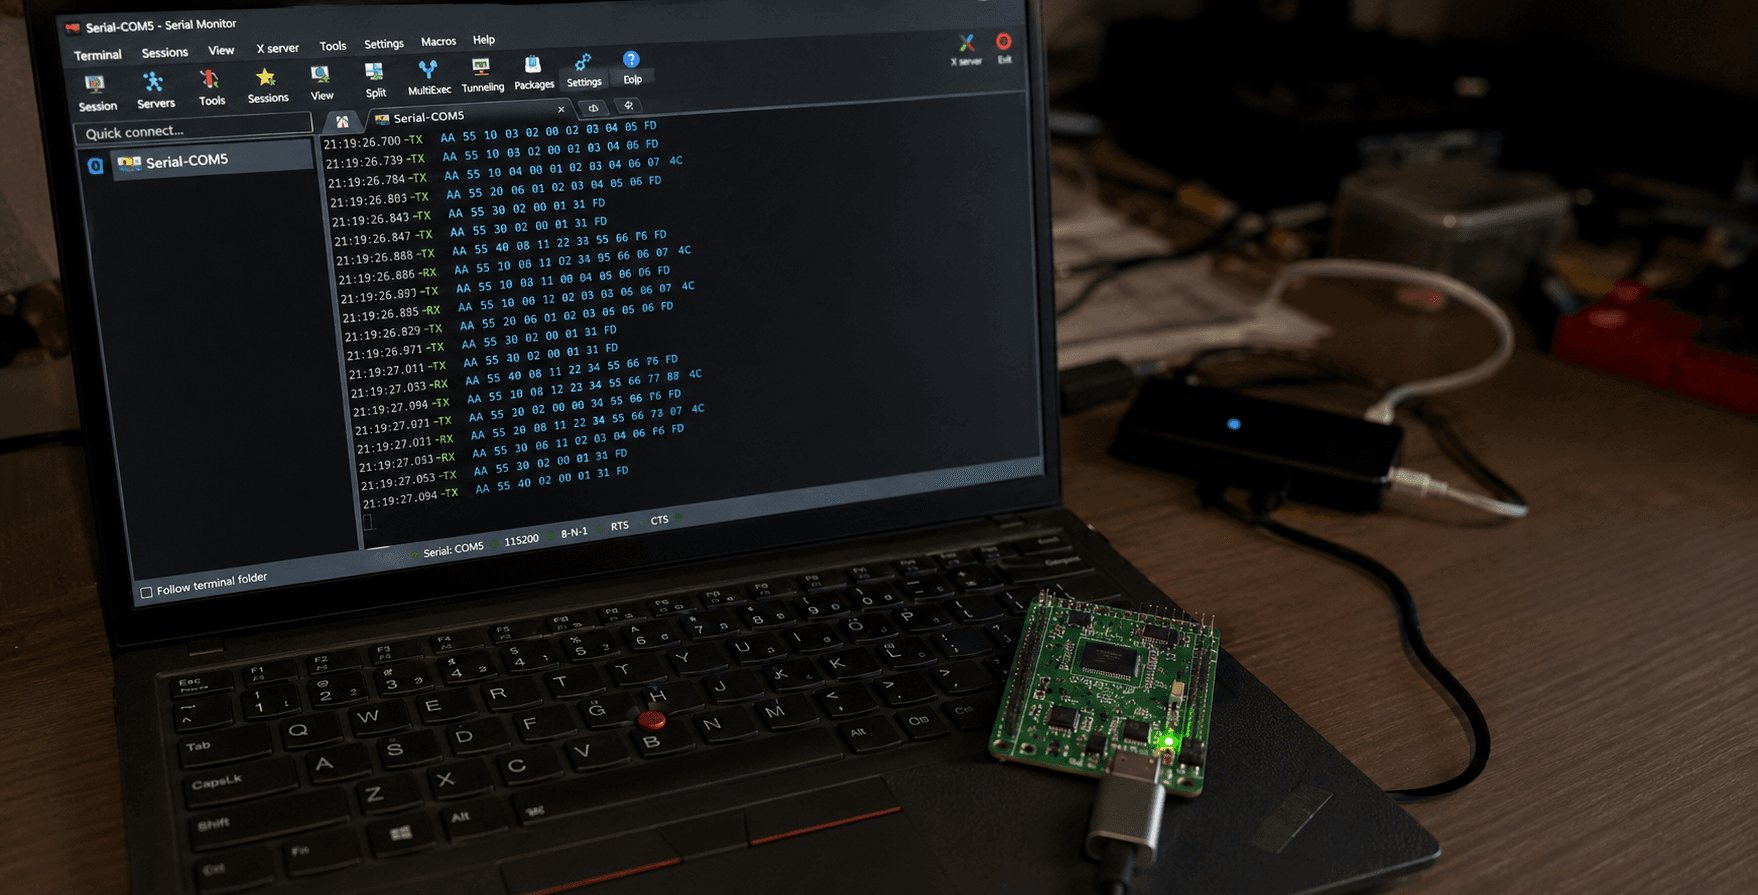
No launch files, no nodes, no topics. Just a Type-C cable, a serial terminal, and every byte typed by hand.
LiDAR captures the surrounding environment in real time, giving our robotic platform accurate spatial awareness for perception and navigation.
 Mr. Bill LamDirector, ADAS & Functional Safety
Academic degree: Master in Software Engineering (AI)
 Mr. Binh PhuongPrincipal Embedded Systems Engineer — IoT & Telematics
Academic degree: Master in Electronics & Telecom
 Mr. Hoang NguyenPrincipal Technical Lead — ADAS Simulation & SDV
Academic degree: Master in Computer Engineering
 Mr. Dinh BuiPrincipal Robotics Engineer — Perception & Decision Making
Academic degree: PhD & MS in Electrical & Computer Eng.
 Mr. Trong NguyenSenior ADAS & SDV Software Engineer
Academic degree: B.Eng. Electronics & Telecom
 Mr. Kien LeSenior ADAS Perception Engineer
Academic degree: B.Eng. Mechatronics
 Mr. Nhan BuiSenior ADAS & SDV Software Engineer
Academic degree: B.Eng. Electronics & Telecom
 Mr. Hoang HuynhSenior Embedded Software Engineer — AUTOSAR & Cybersecurity
Academic degree: Master in Mechatronics Engineering
 Mr. Hung NguyenSenior Embedded Software Engineer
Academic degree: B.Eng. Mechatronics