 BlinkThorLabs
A Week Teaching MentorPi to Follow a Line (And Actually Understanding Why It Works)
Monday to Friday, one road mat, one stubborn ceiling light, and the moment lane_detect.py finally made sense.
45 write-ups across 8 disciplines, newest first.
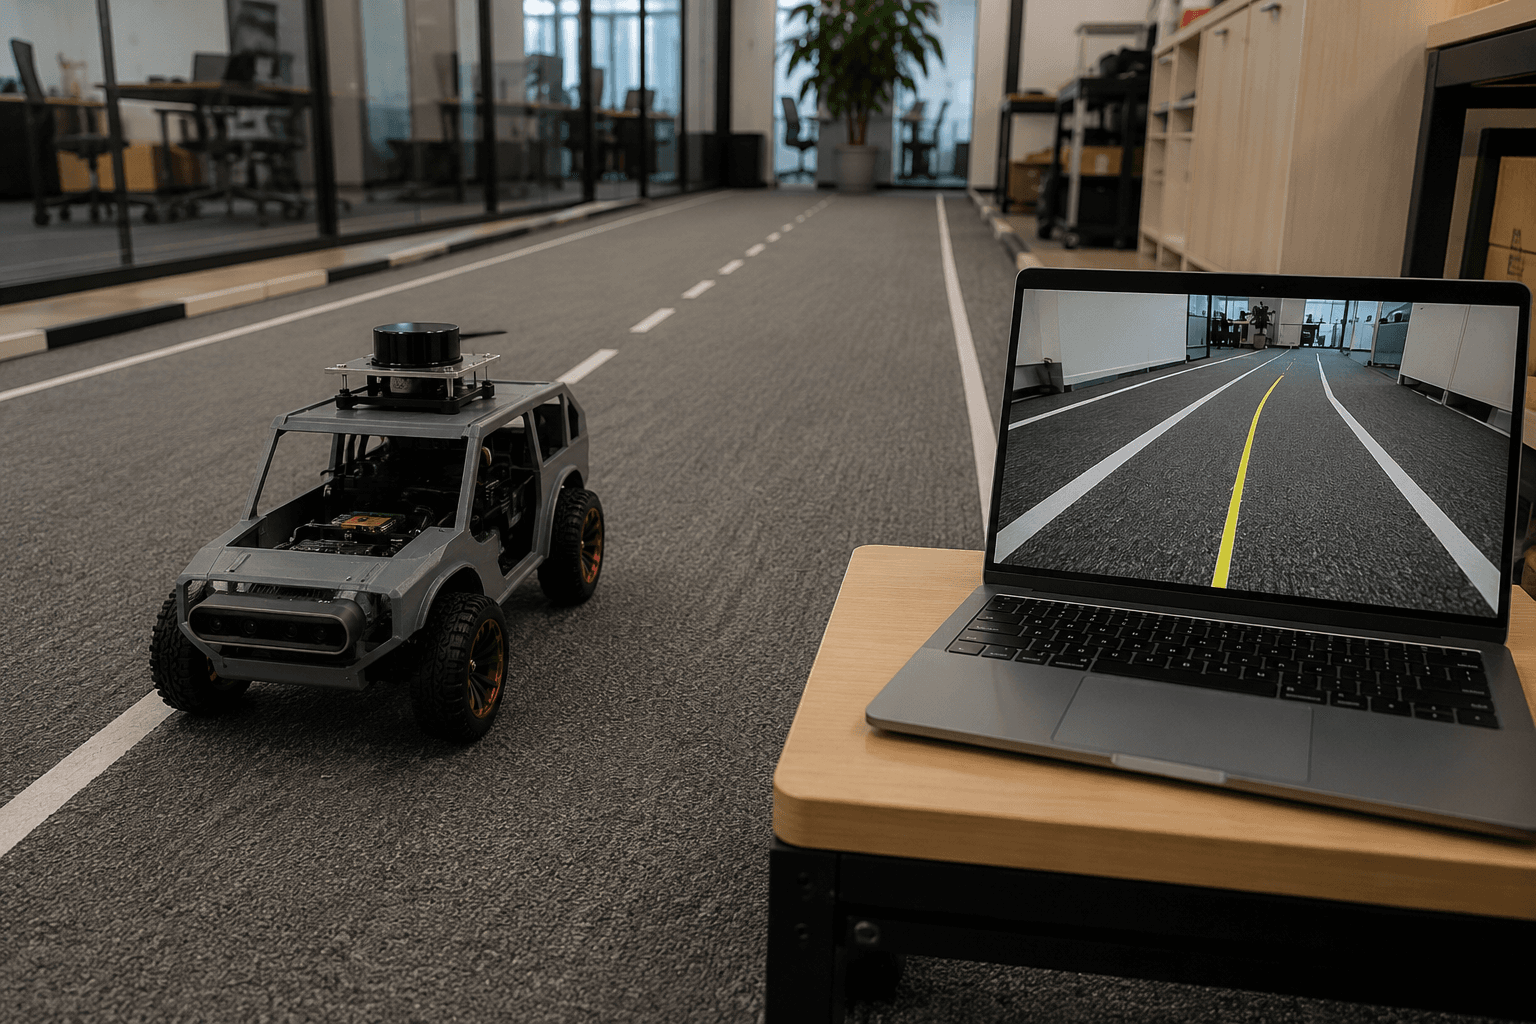
Monday to Friday, one road mat, one stubborn ceiling light, and the moment lane_detect.py finally made sense.
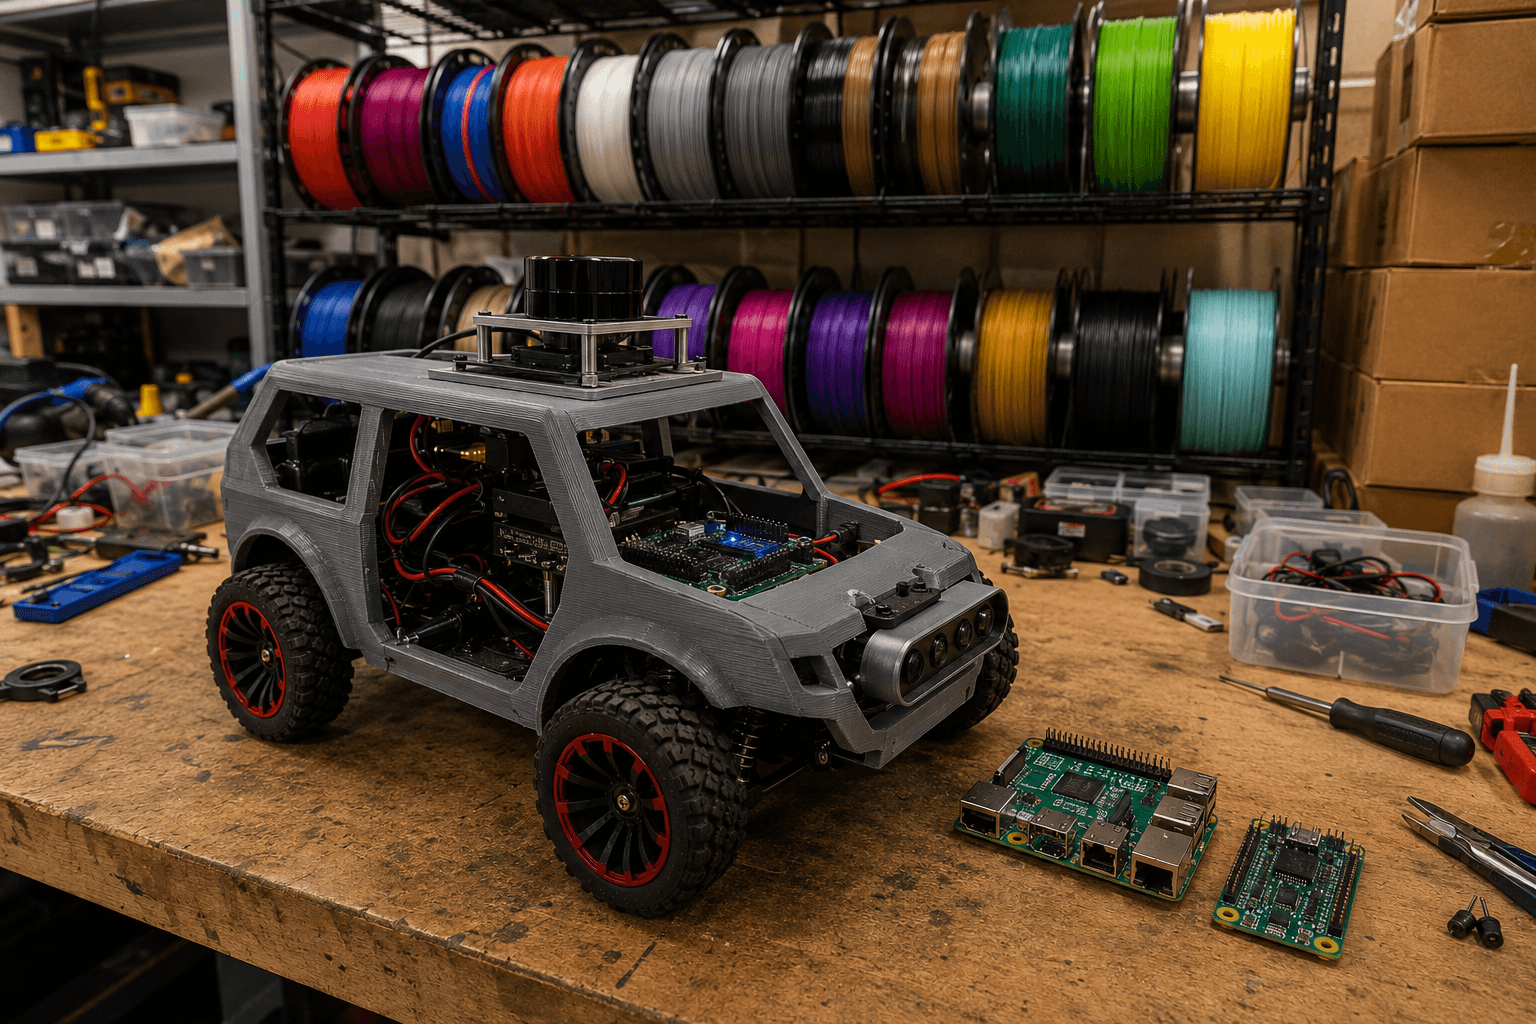
Ackermann chassis, ROS2 on a Raspberry Pi 5, and the specific joy of hearing a buzzer confirm your first boot actually worked.
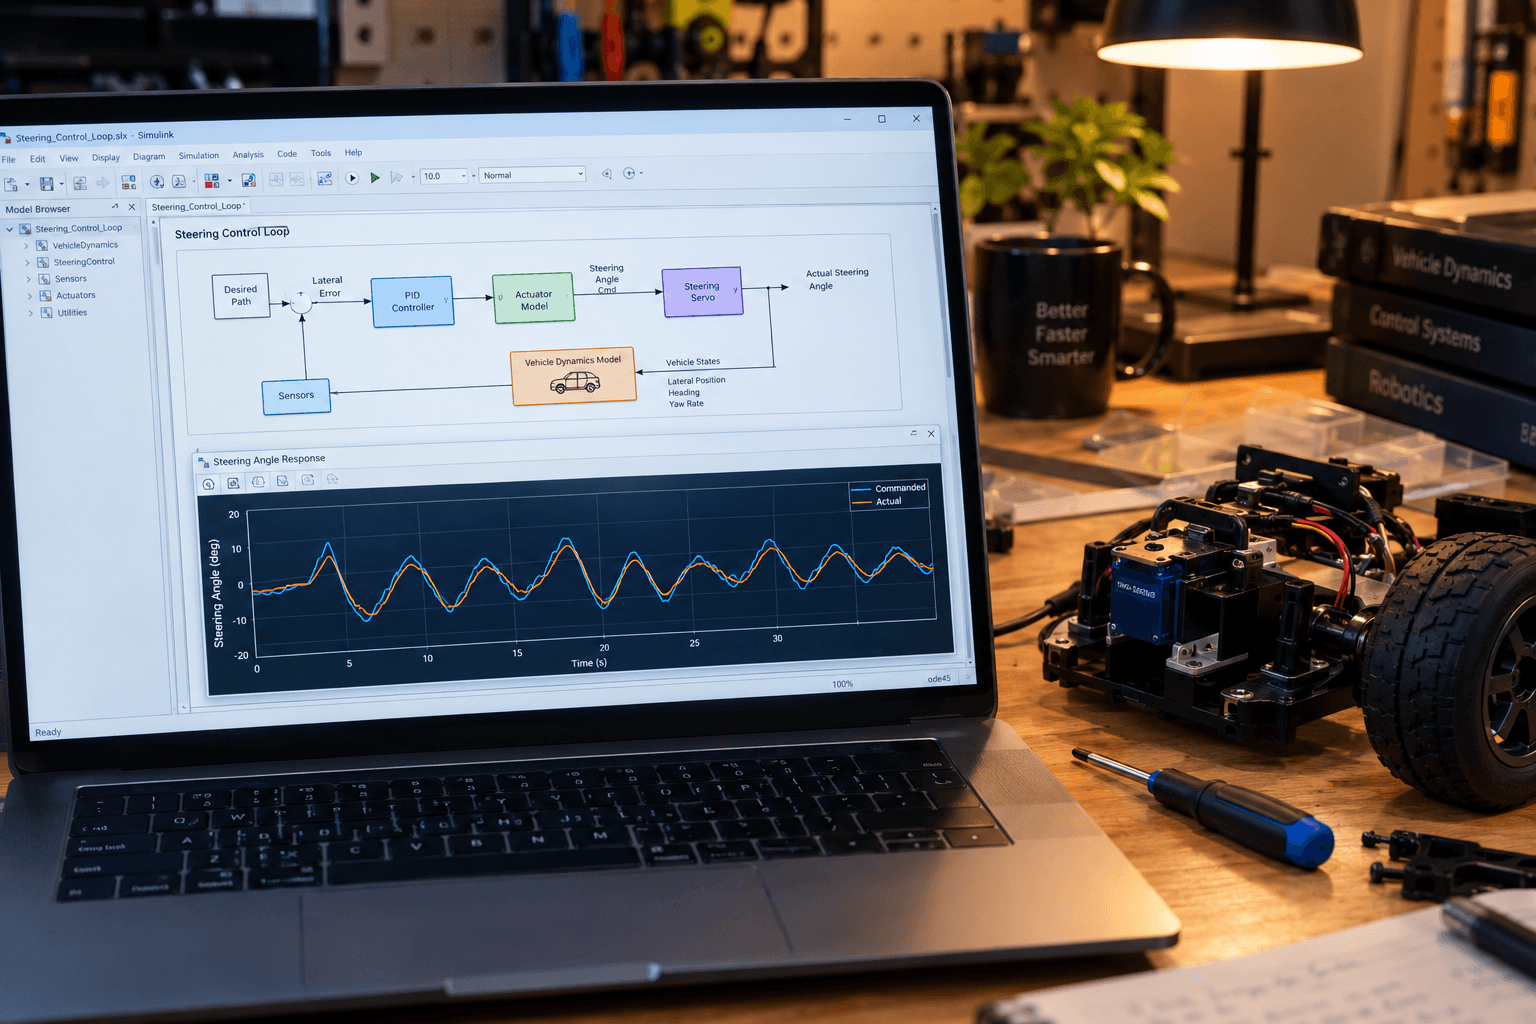
I was ready to blame the servo. The model had been telling me it was something else for two days.
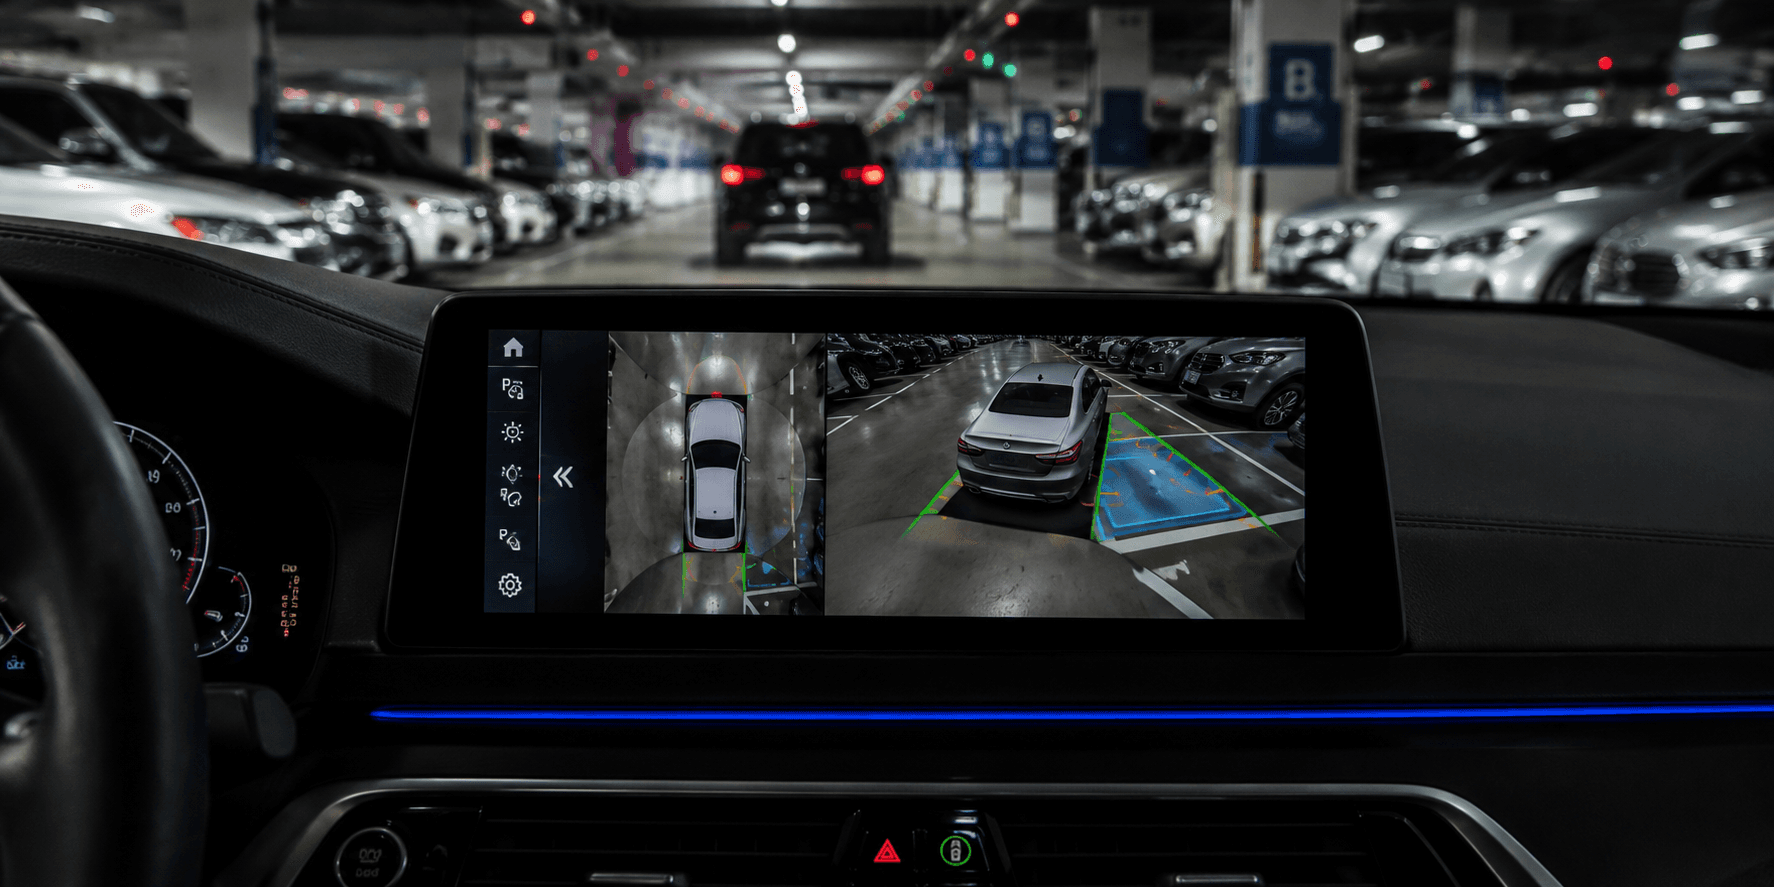
The trajectory math was solved decades ago. Here's where the actual engineering effort goes instead.
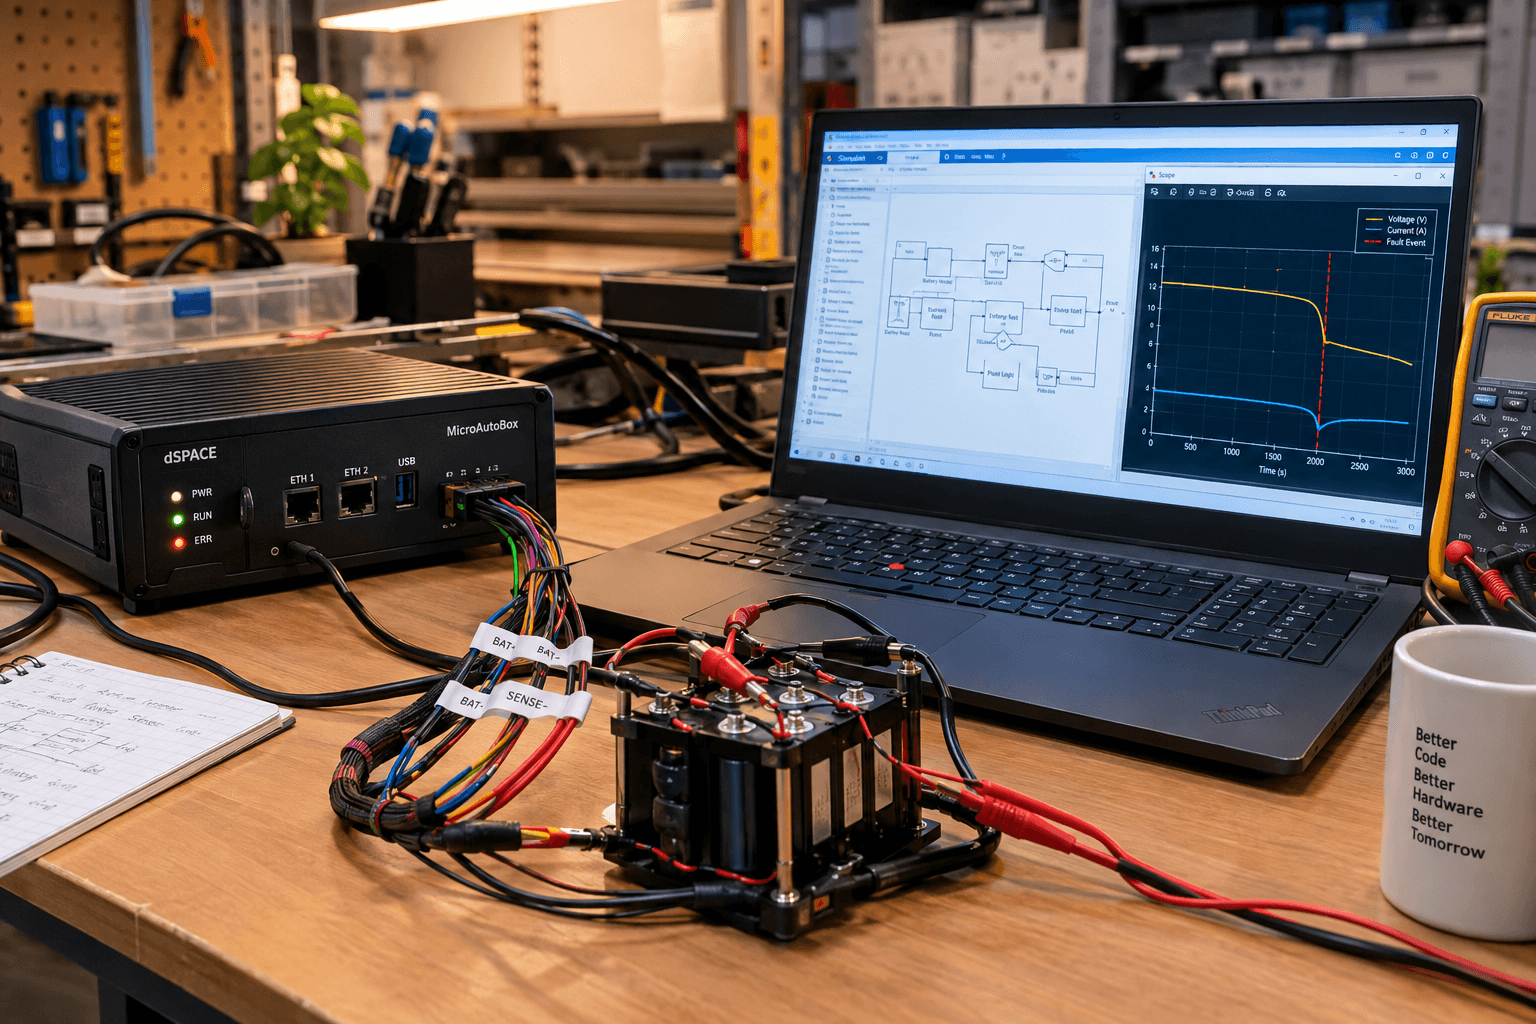
The real cell arrived three weeks late. By the time it showed up, the simulated one had already failed on us four times — for free.
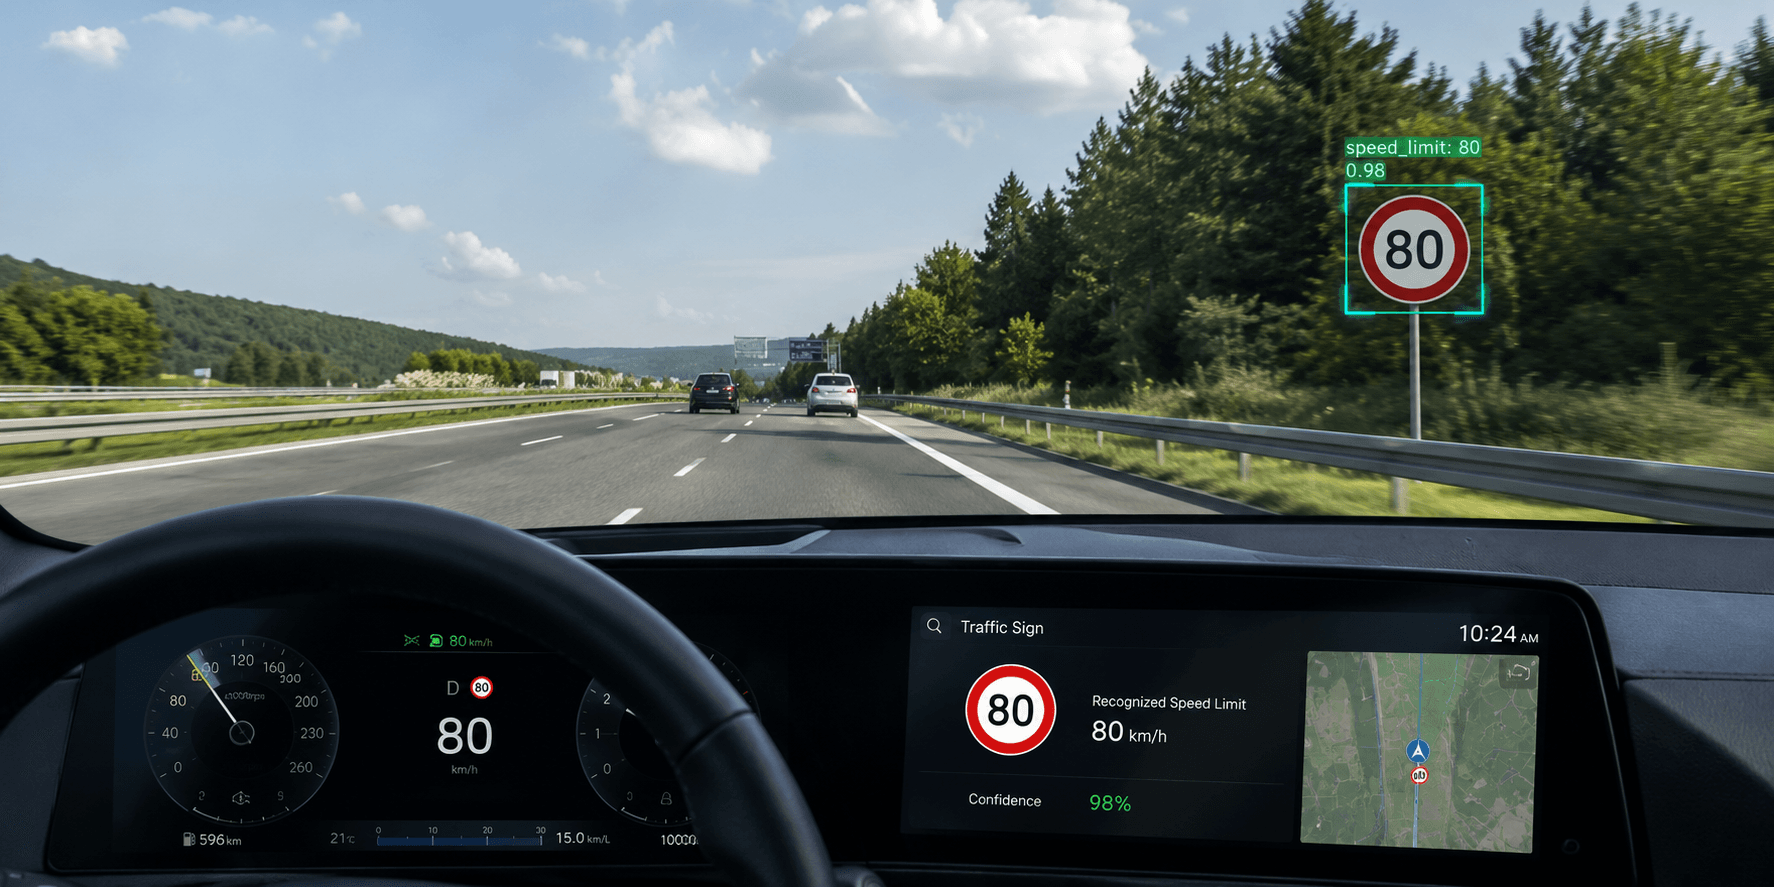
Detection finds it, classification names it, temporal fusion decides whether to trust it. Here's the full path.
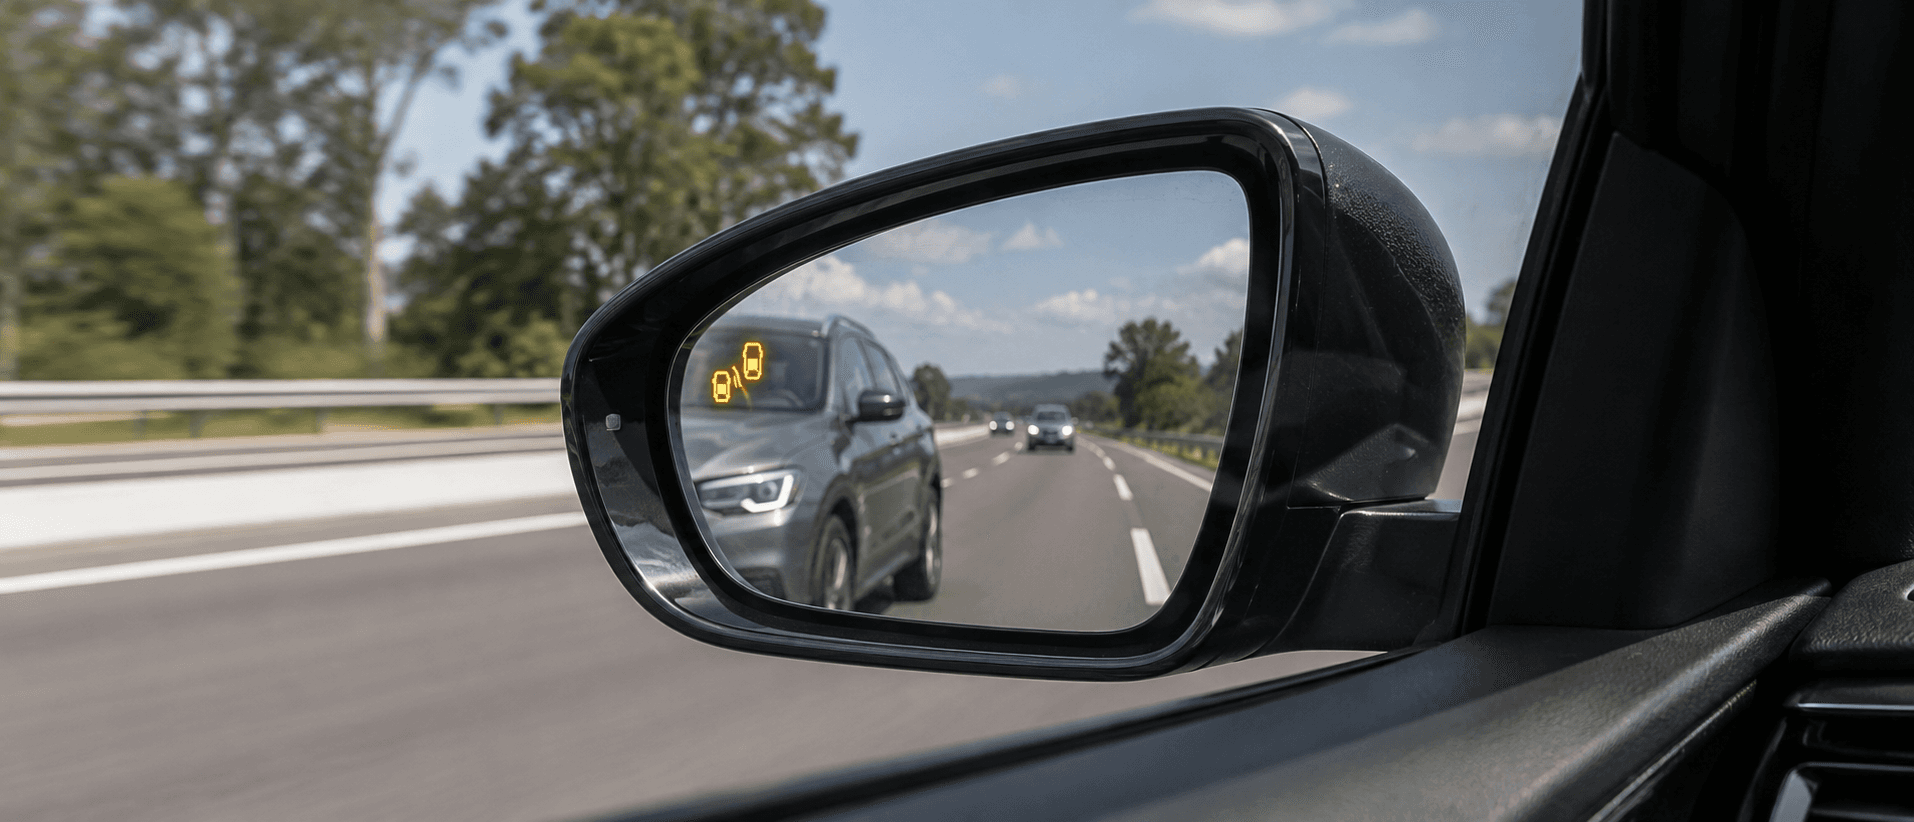
Not a driver-facing FAQ. A corrective for the misconceptions that show up in our own sales decks first.
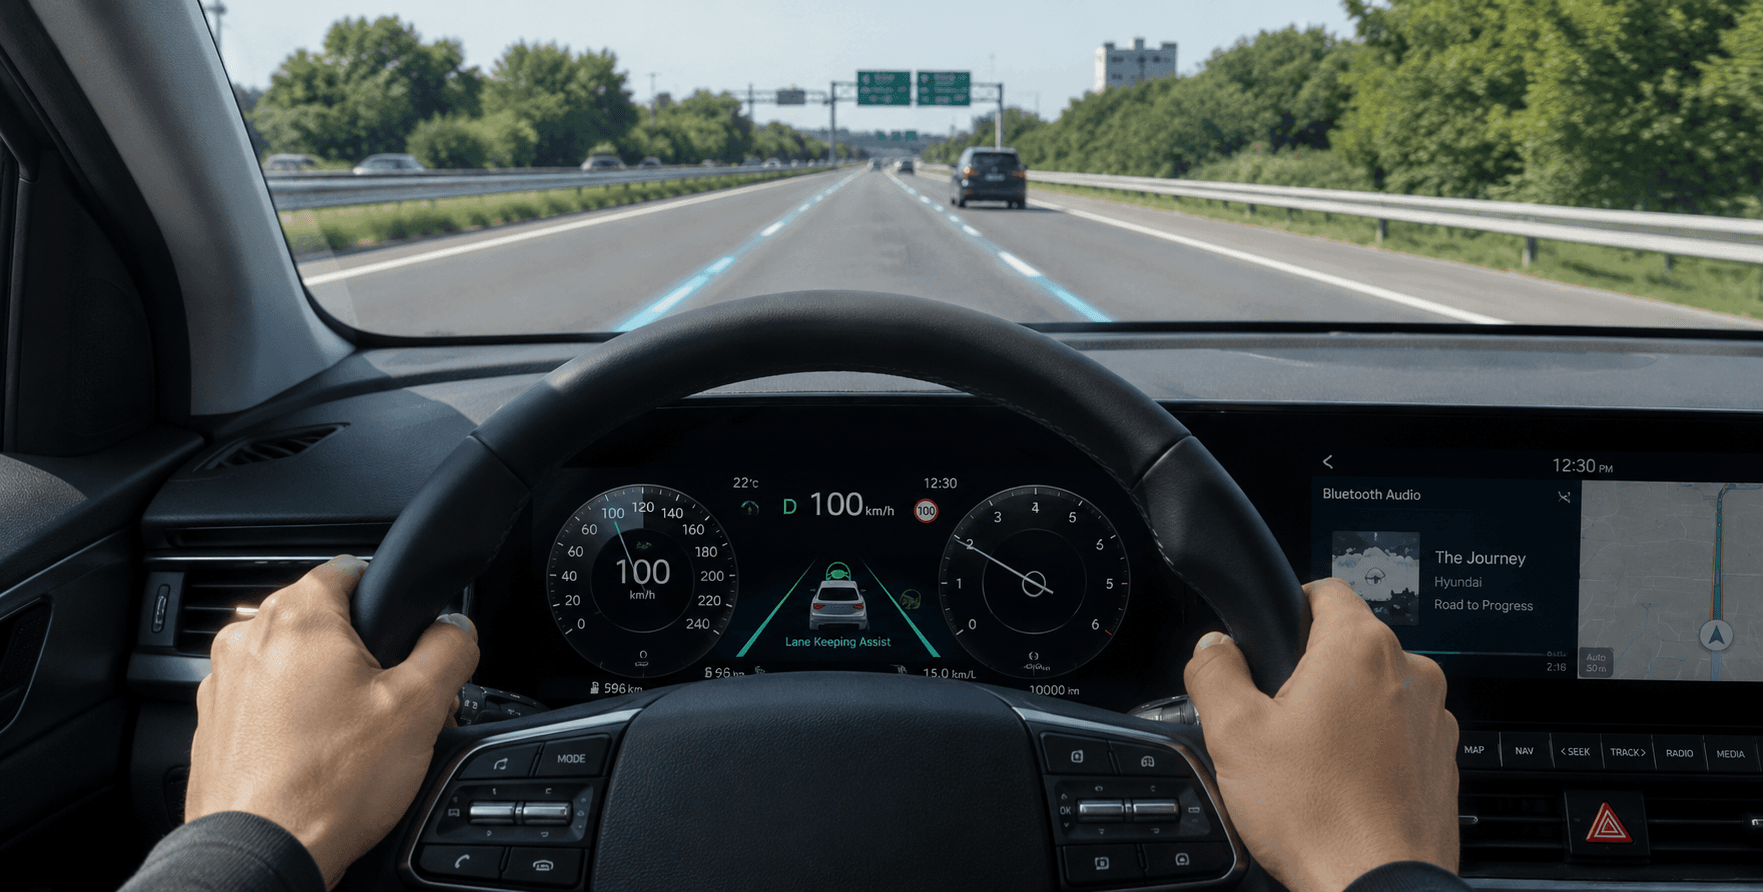
A conversation that actually happened, more or less, over a whiteboard and two cold coffees.
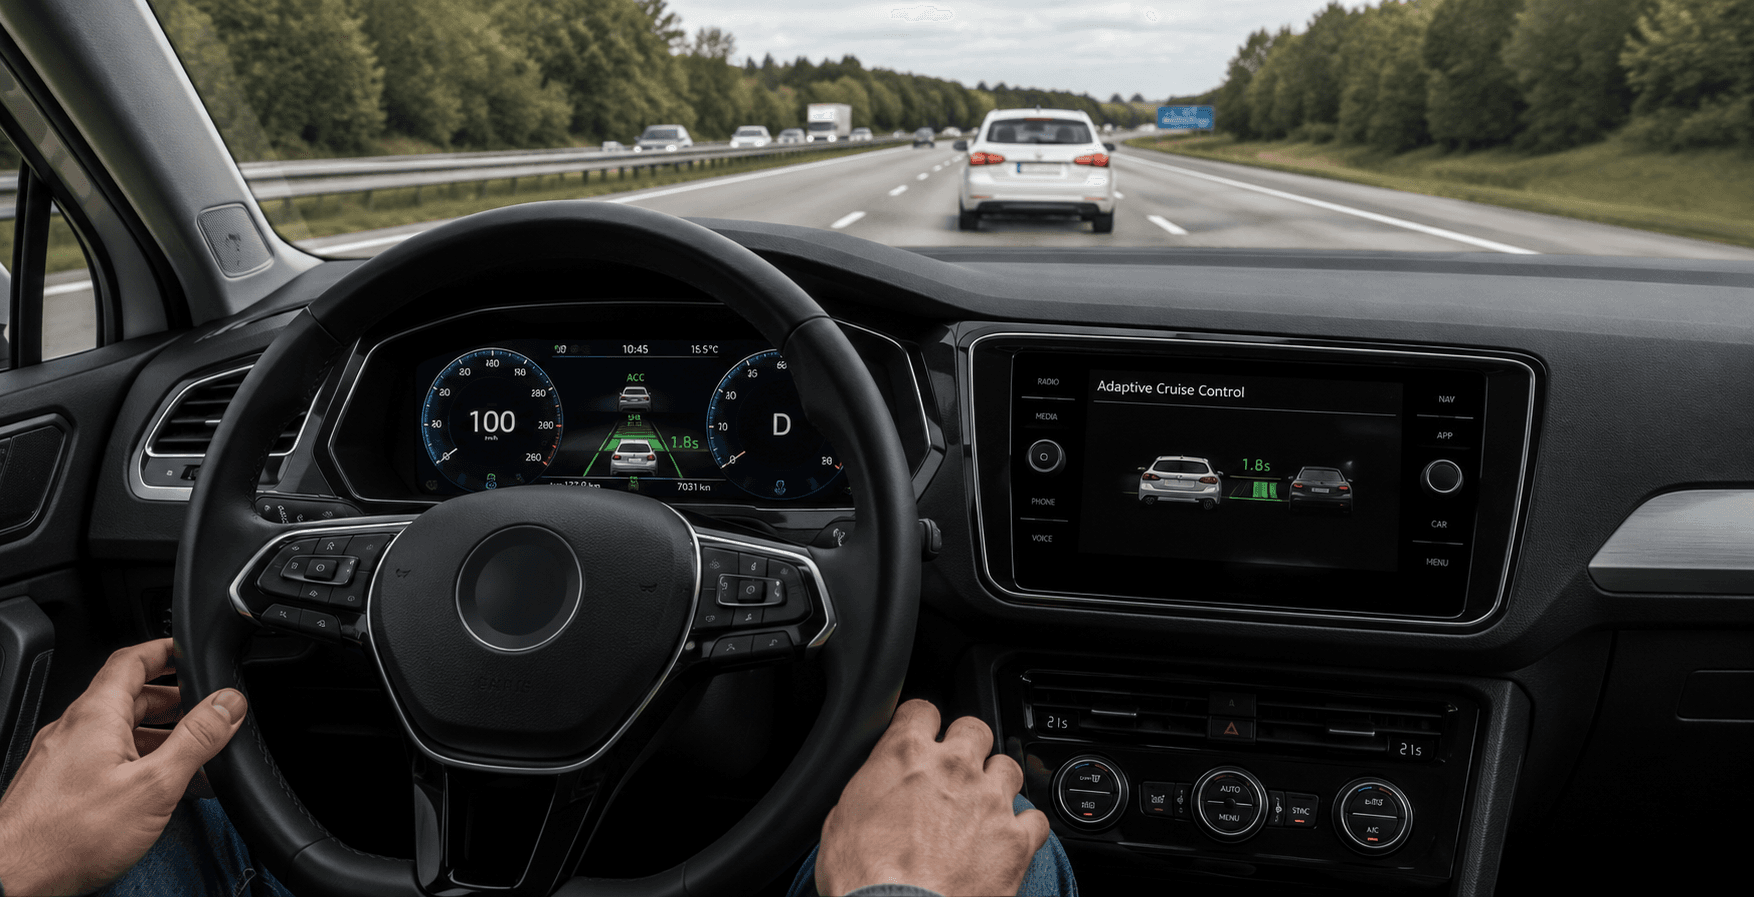
Process noise tuning matters more than your motion model — and jerk matters more than either, if you're the one sitting in the passenger seat.